-
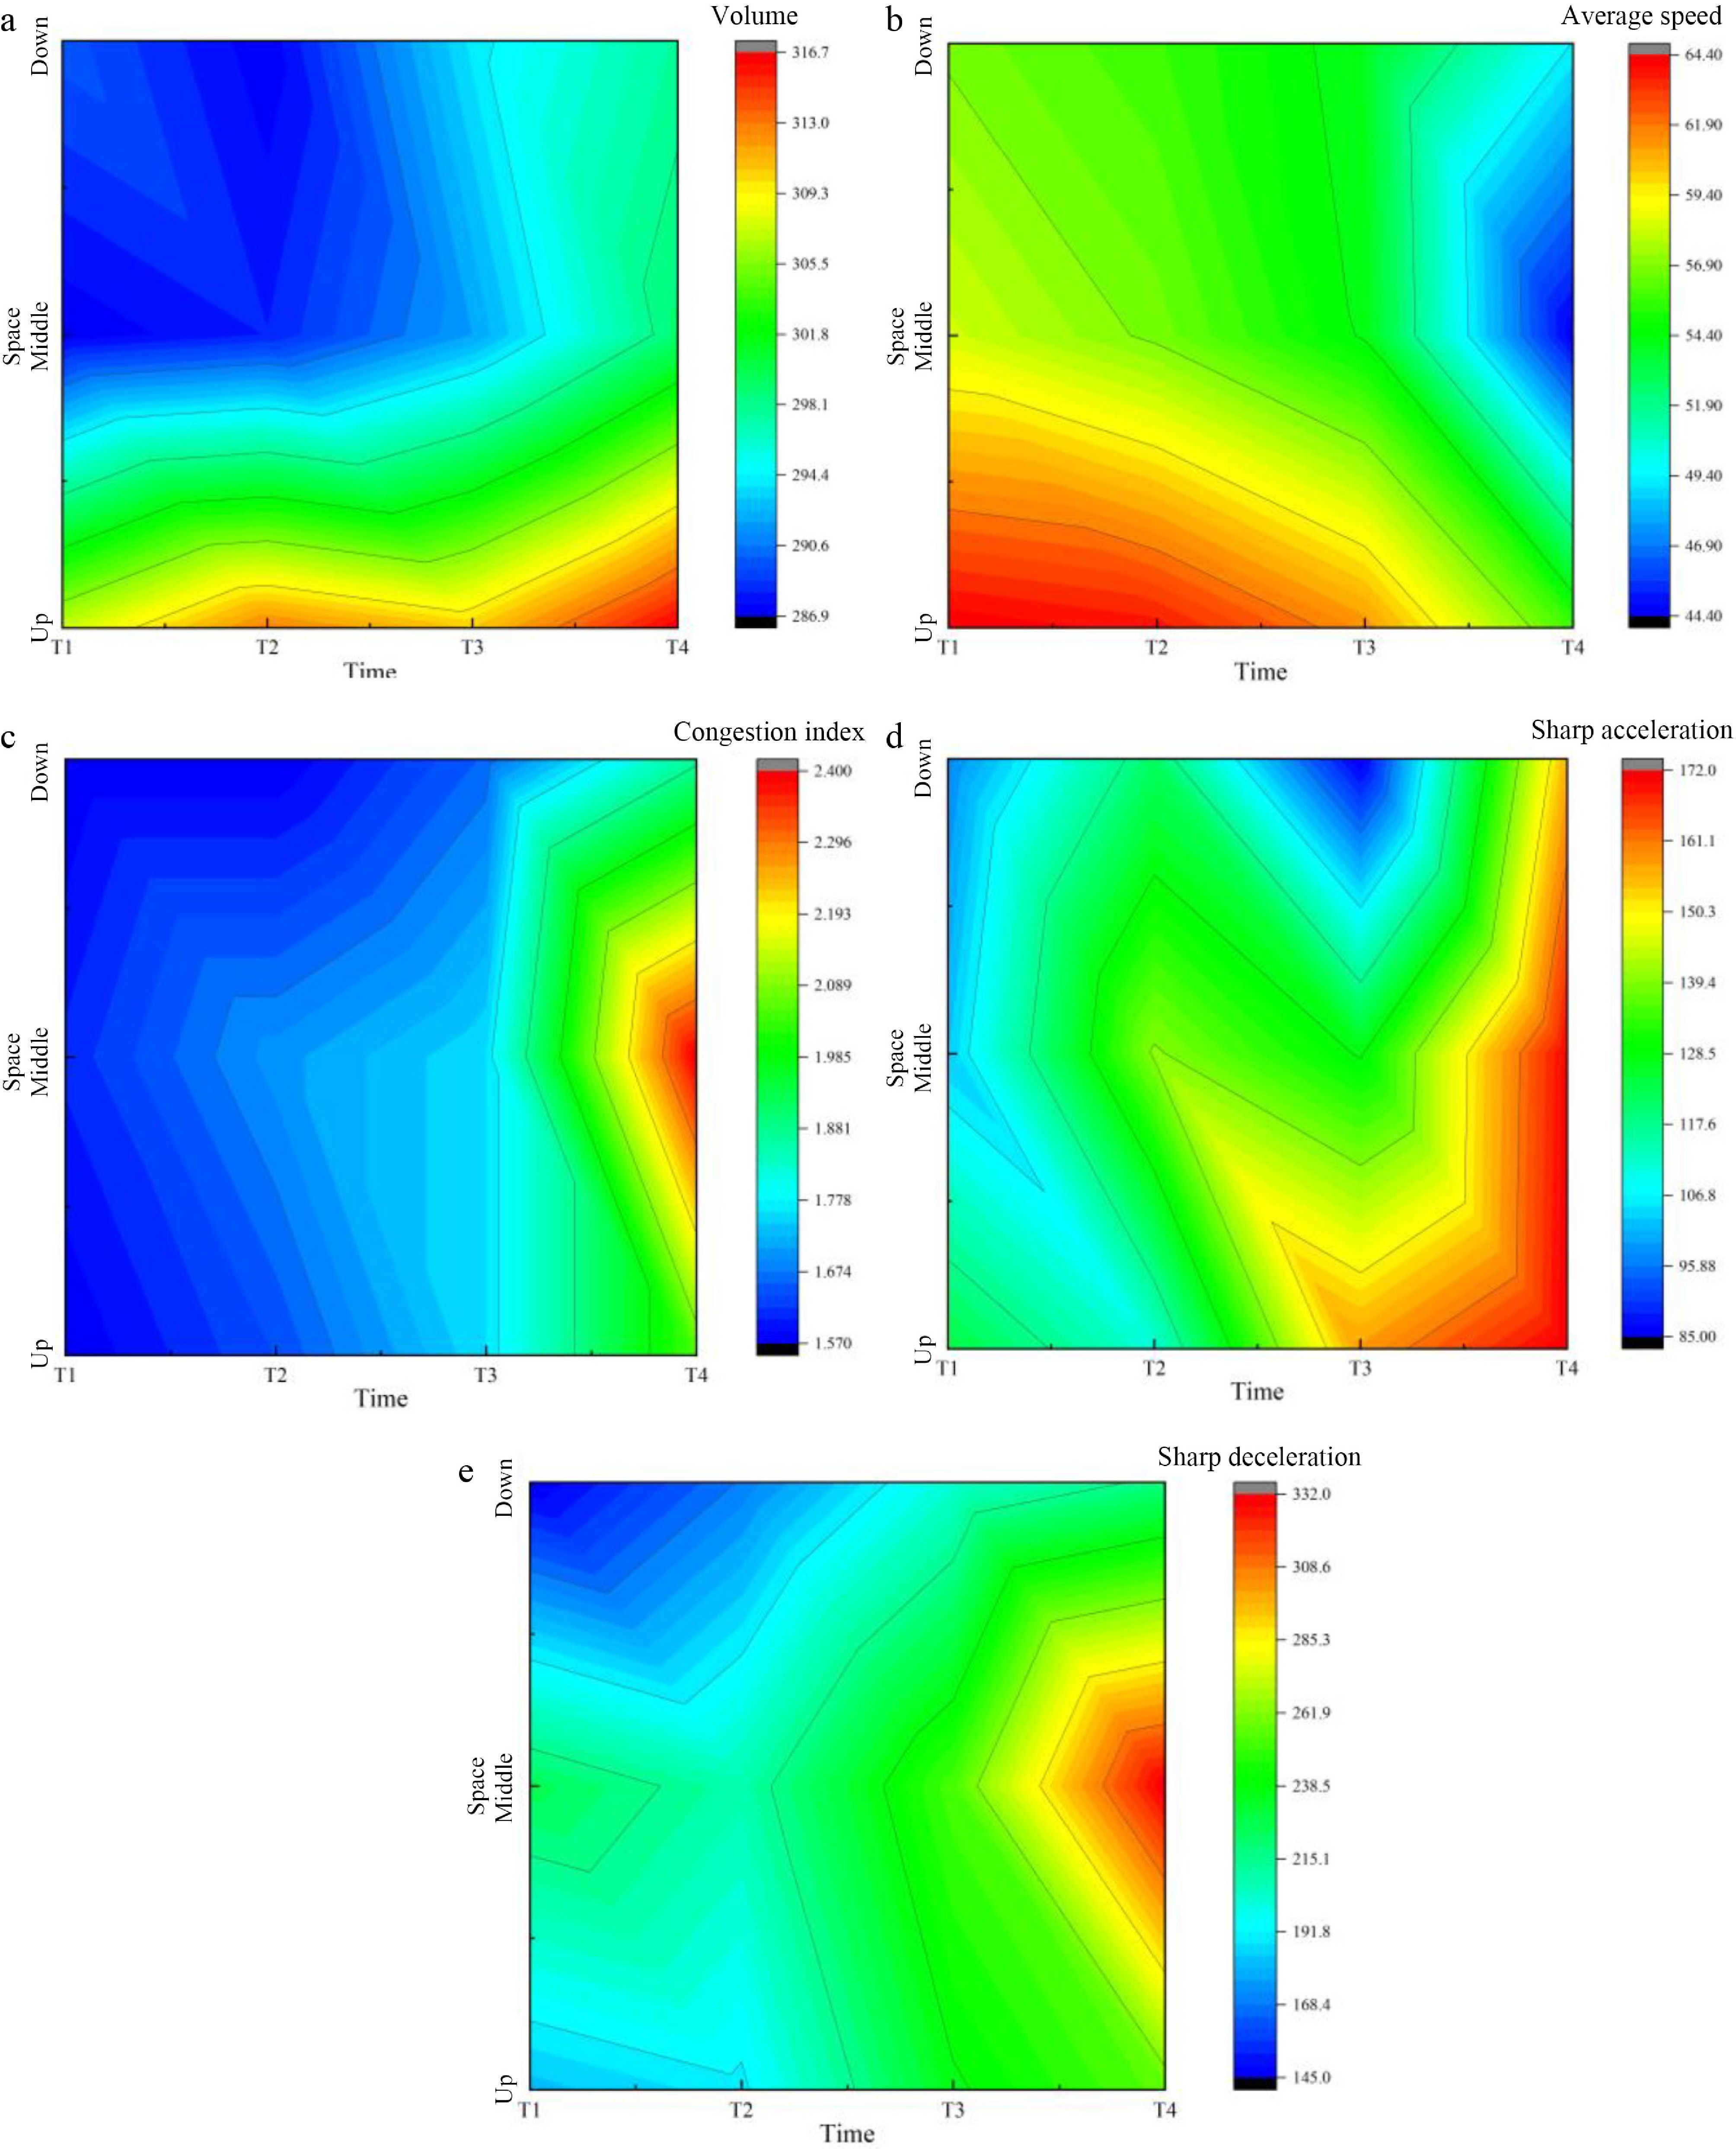
Figure 1.
Spatiotemporal distribution of traffic status and risky driving behavior characteristics during the crashes. (a) Traffic volume. (b) Average speed. (c) Congestion index. (d) Sharp acceleration. (e) Sharp deceleration.
-
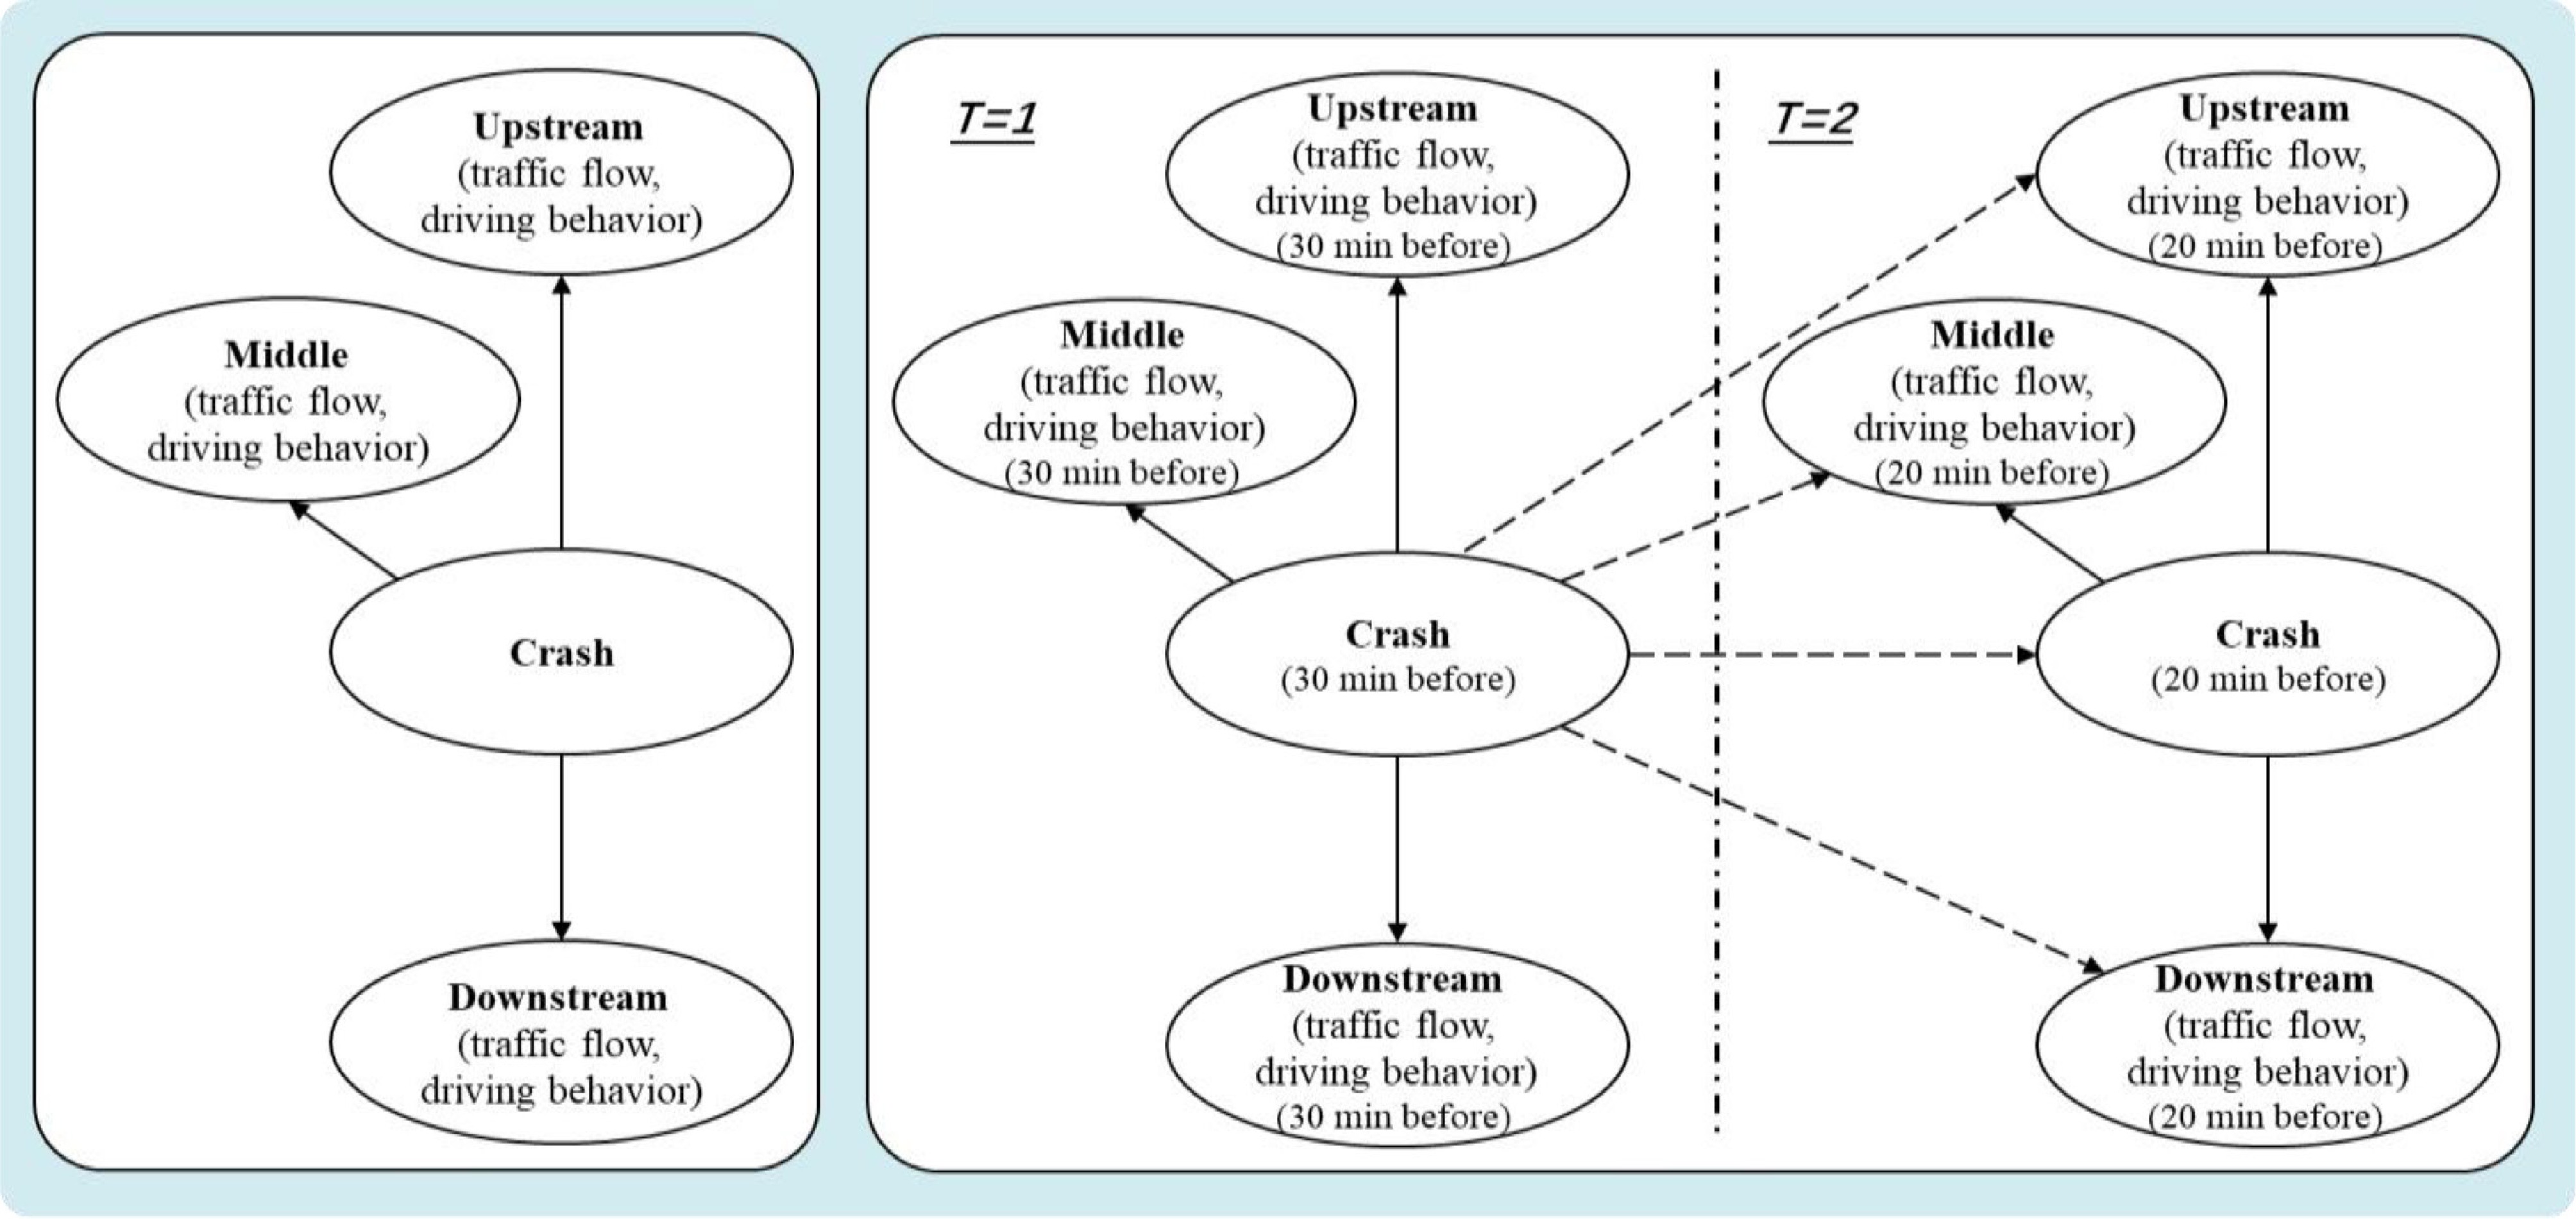
Figure 2.
The structure of Bayesian networks.
-
Figure 3.
Spatiotemporal probability distribution of traffic status and risky driving behaviors in non-crash conditions. (a) Distribution of traffic status and risky driving behaviors from T1 to T2 in the upstream, middle, and downstream segments in non-crash conditions. (b) Distribution of traffic status and risky driving behaviors from T2 to T3 in the upstream, middle, and downstream segments in non-crash conditions. (c) Distribution of traffic status and risky driving behaviors states from T3 to T4 in the upstream, middle, and downstream segments in non-crash conditions.
-
Figure 4.
Spatiotemporal probability distribution of traffic status and risky driving behaviors in crash conditions. (a) Distribution of traffic status and risky driving behaviors states from T1 to T2 in the upstream, middle, and downstream segments in crash conditions. (b) Distribution of traffic status and risky driving behaviors states from T2 to T3 in the upstream, middle, and downstream segments in crash conditions. (c) Distribution of traffic status and risky driving behaviors states from T3 to T4 in the upstream, middle, and downstream segments in crash conditions.
-
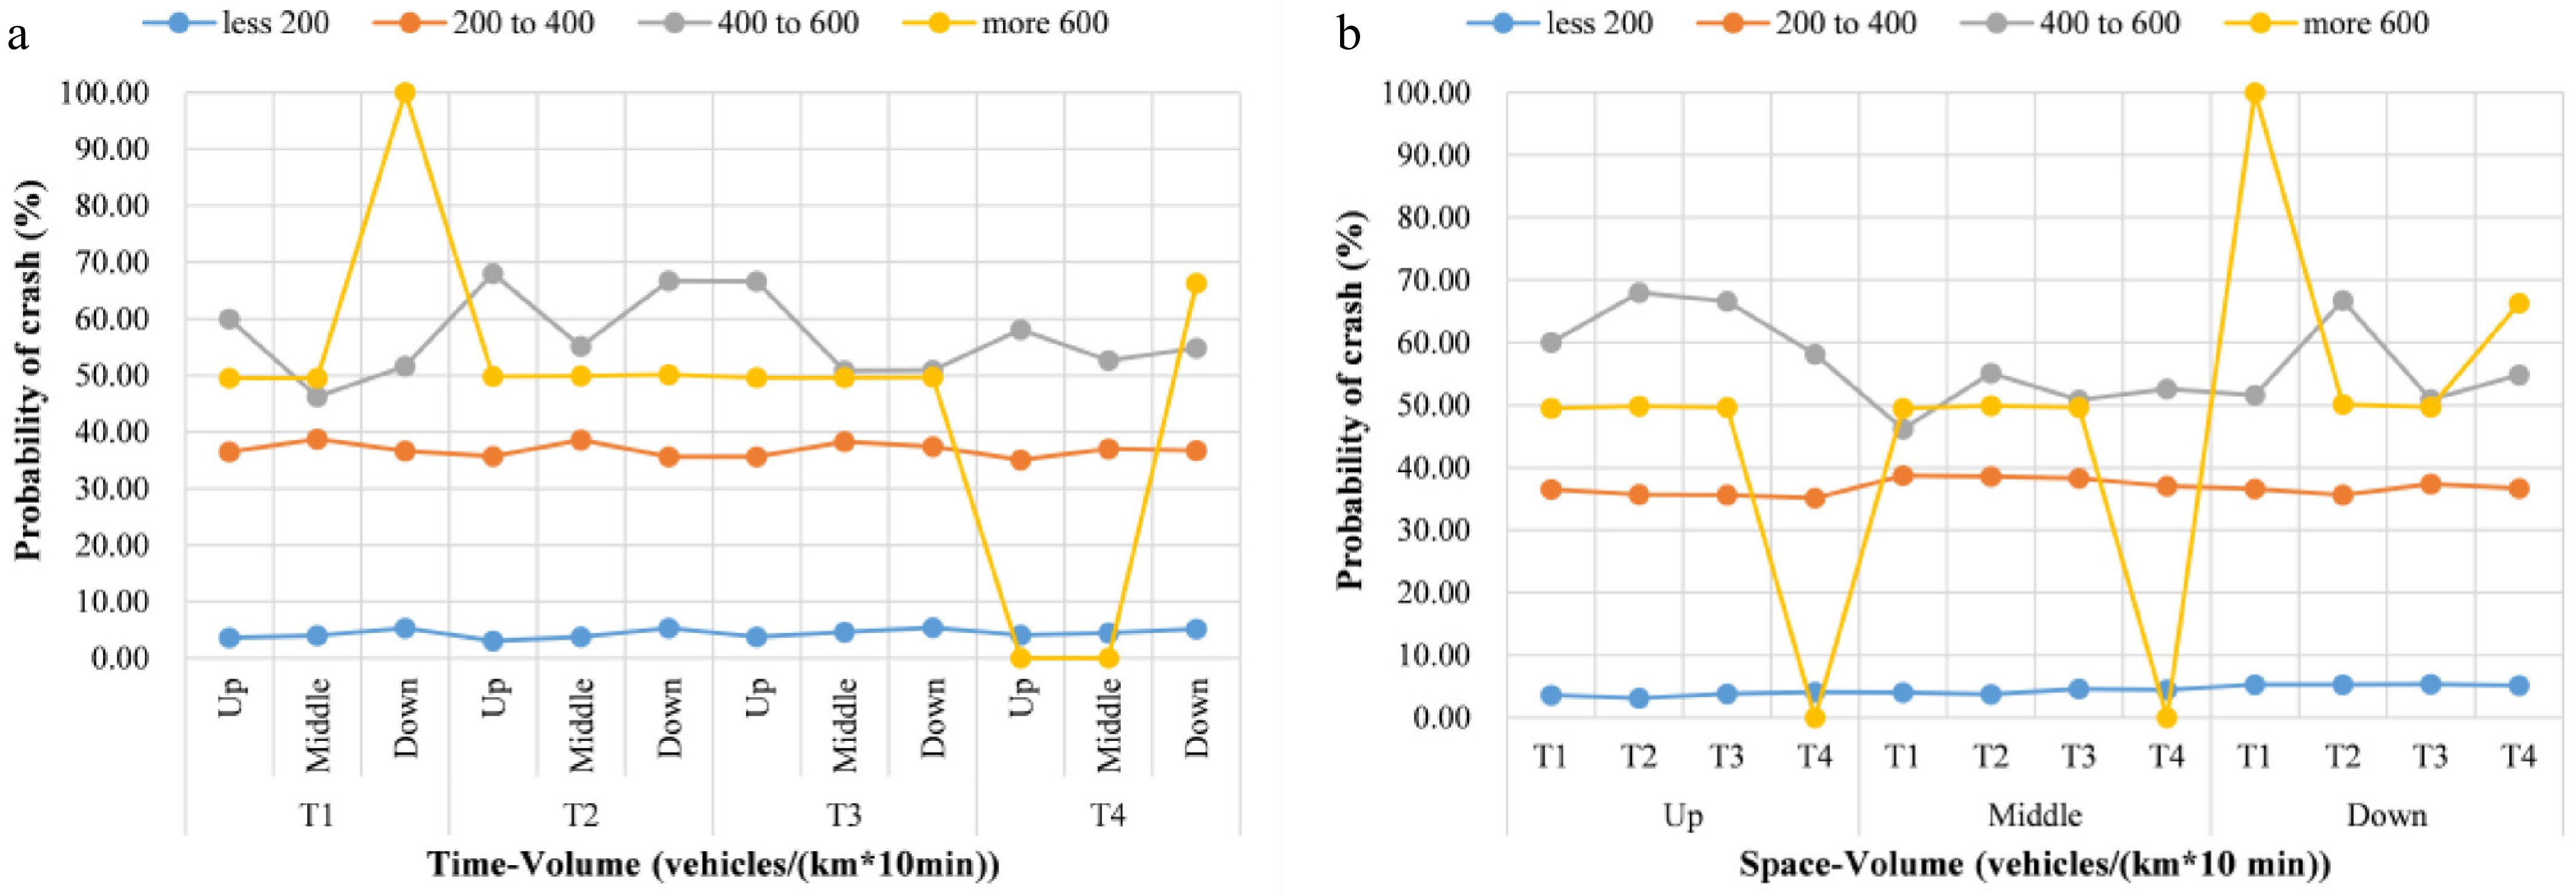
Figure 5.
Effect of a change in traffic volume on crash probability. (a) Temporal variation of traffic volume. (b) Spatial variation of traffic volume.
-
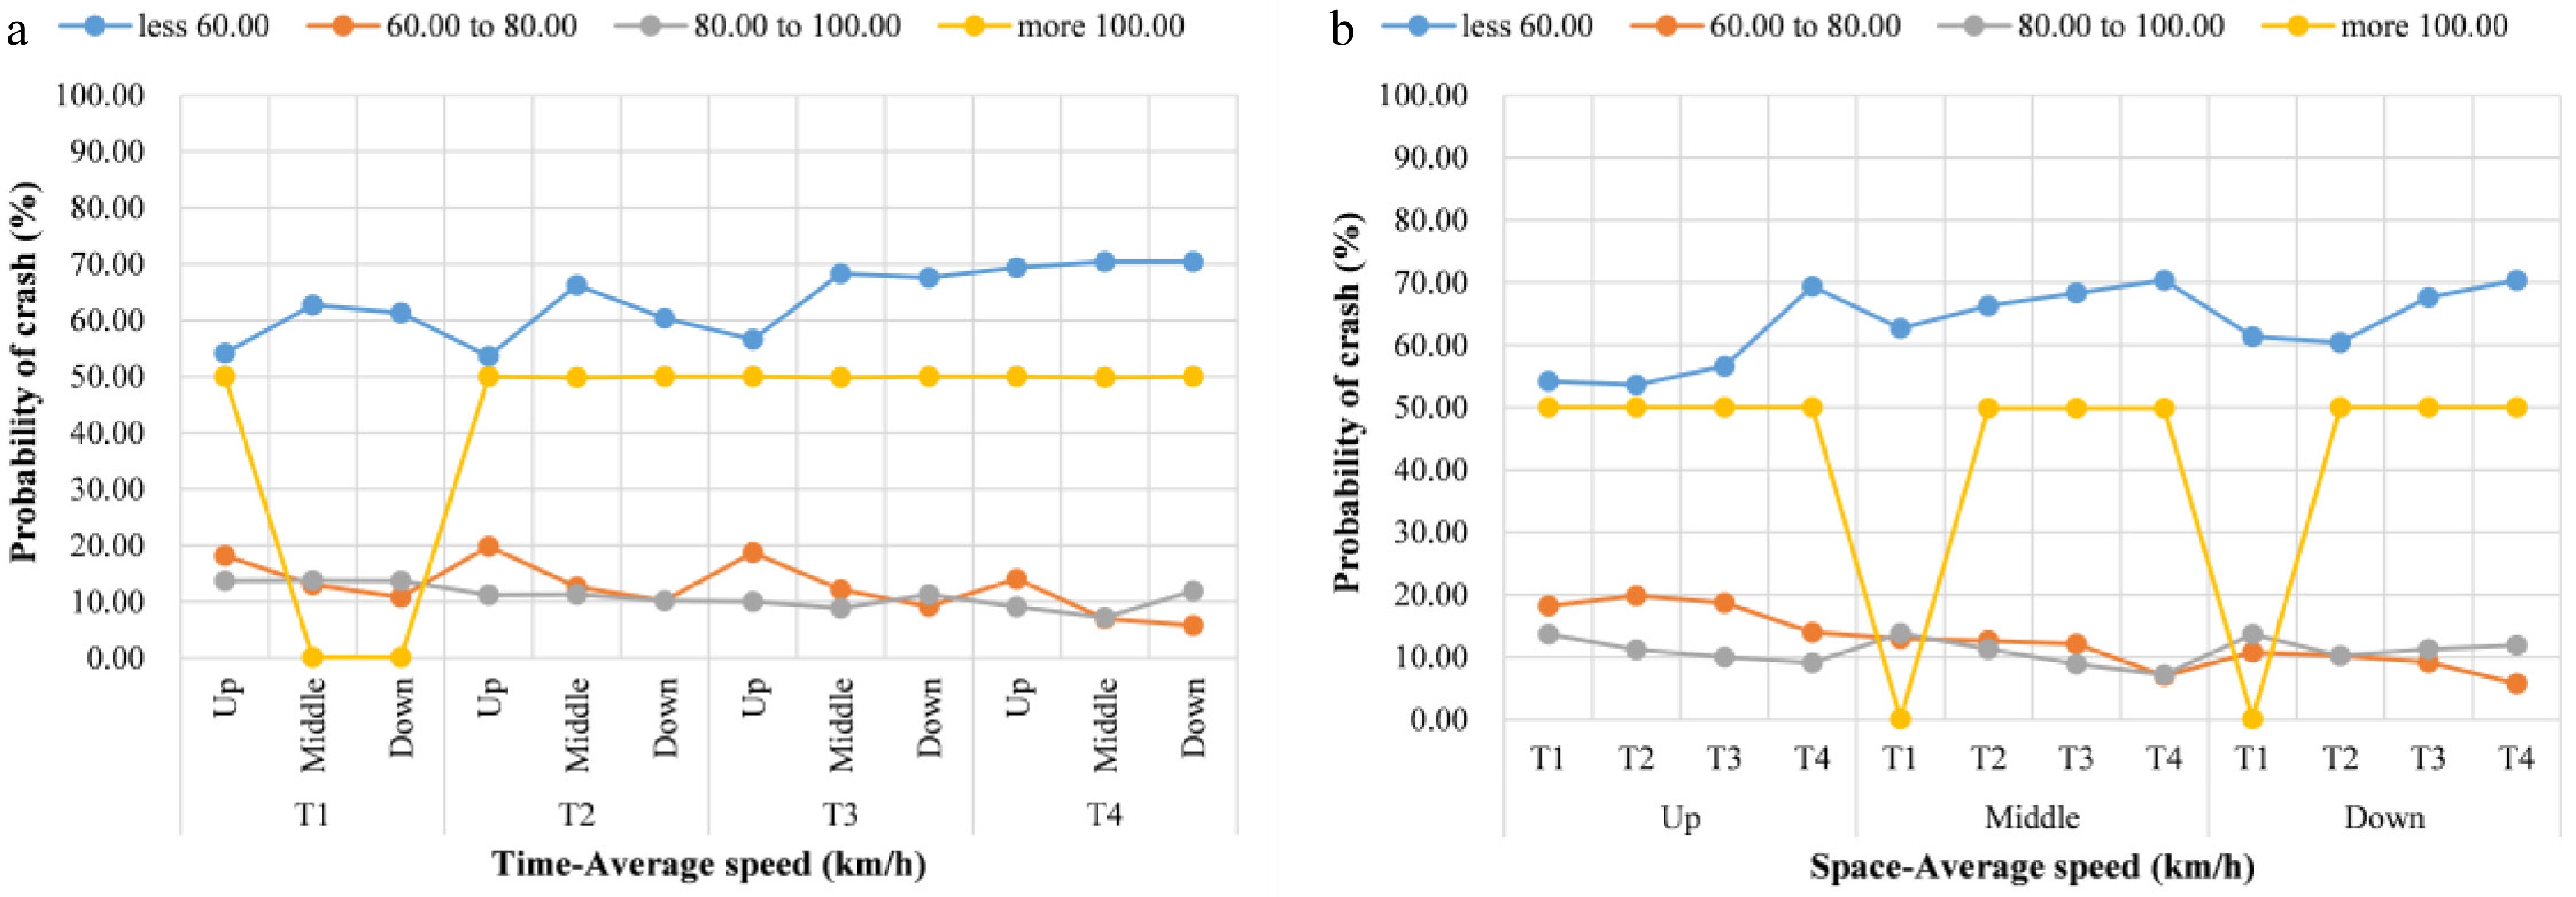
Figure 6.
Effect of the change in average speed on crash probability. (a) Temporal variation of average speed. (b) Spatial variation of average speed.
-
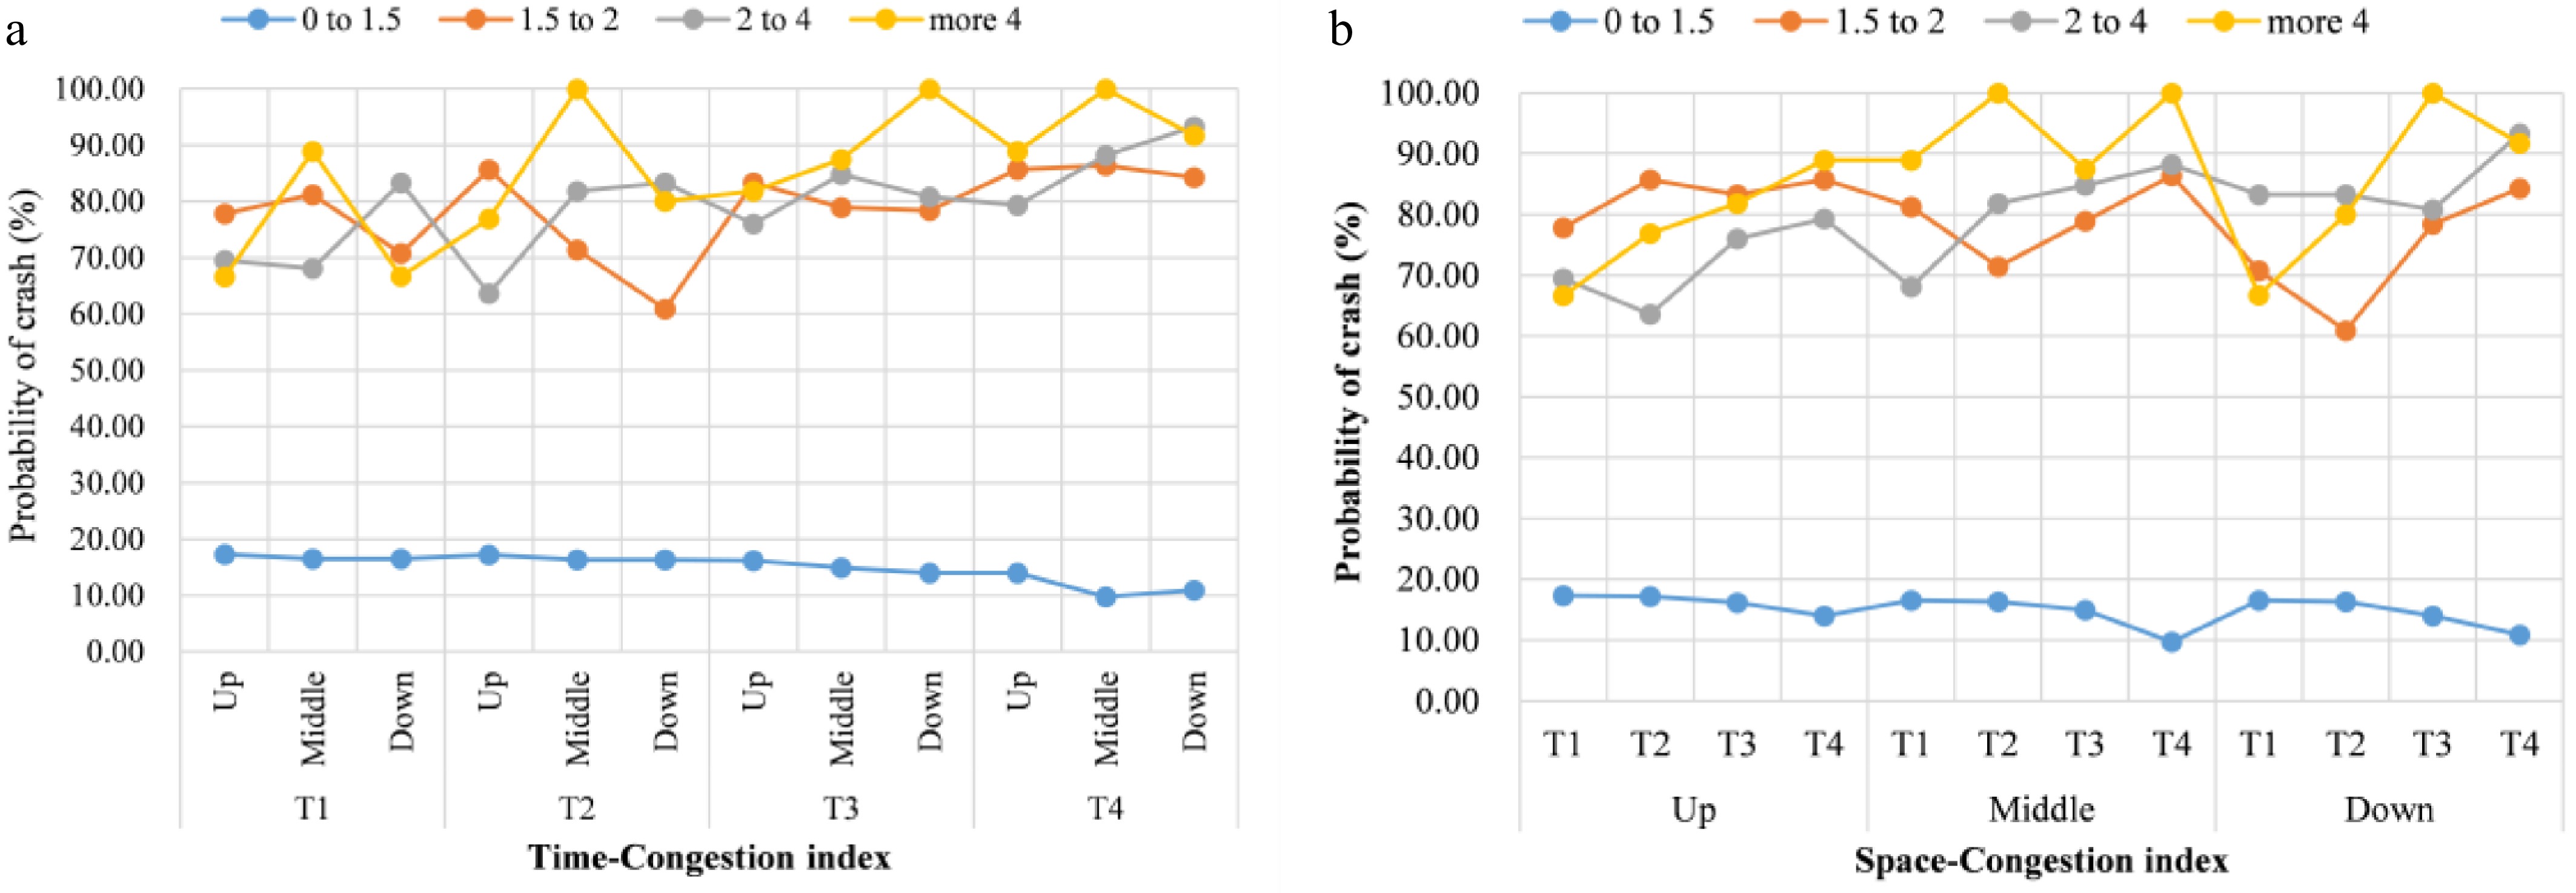
Figure 7.
Effect of a change in the congestion index on crash probability. (a) Temporal variation of congestion index. (b) Spatial variation of congestion index.
-
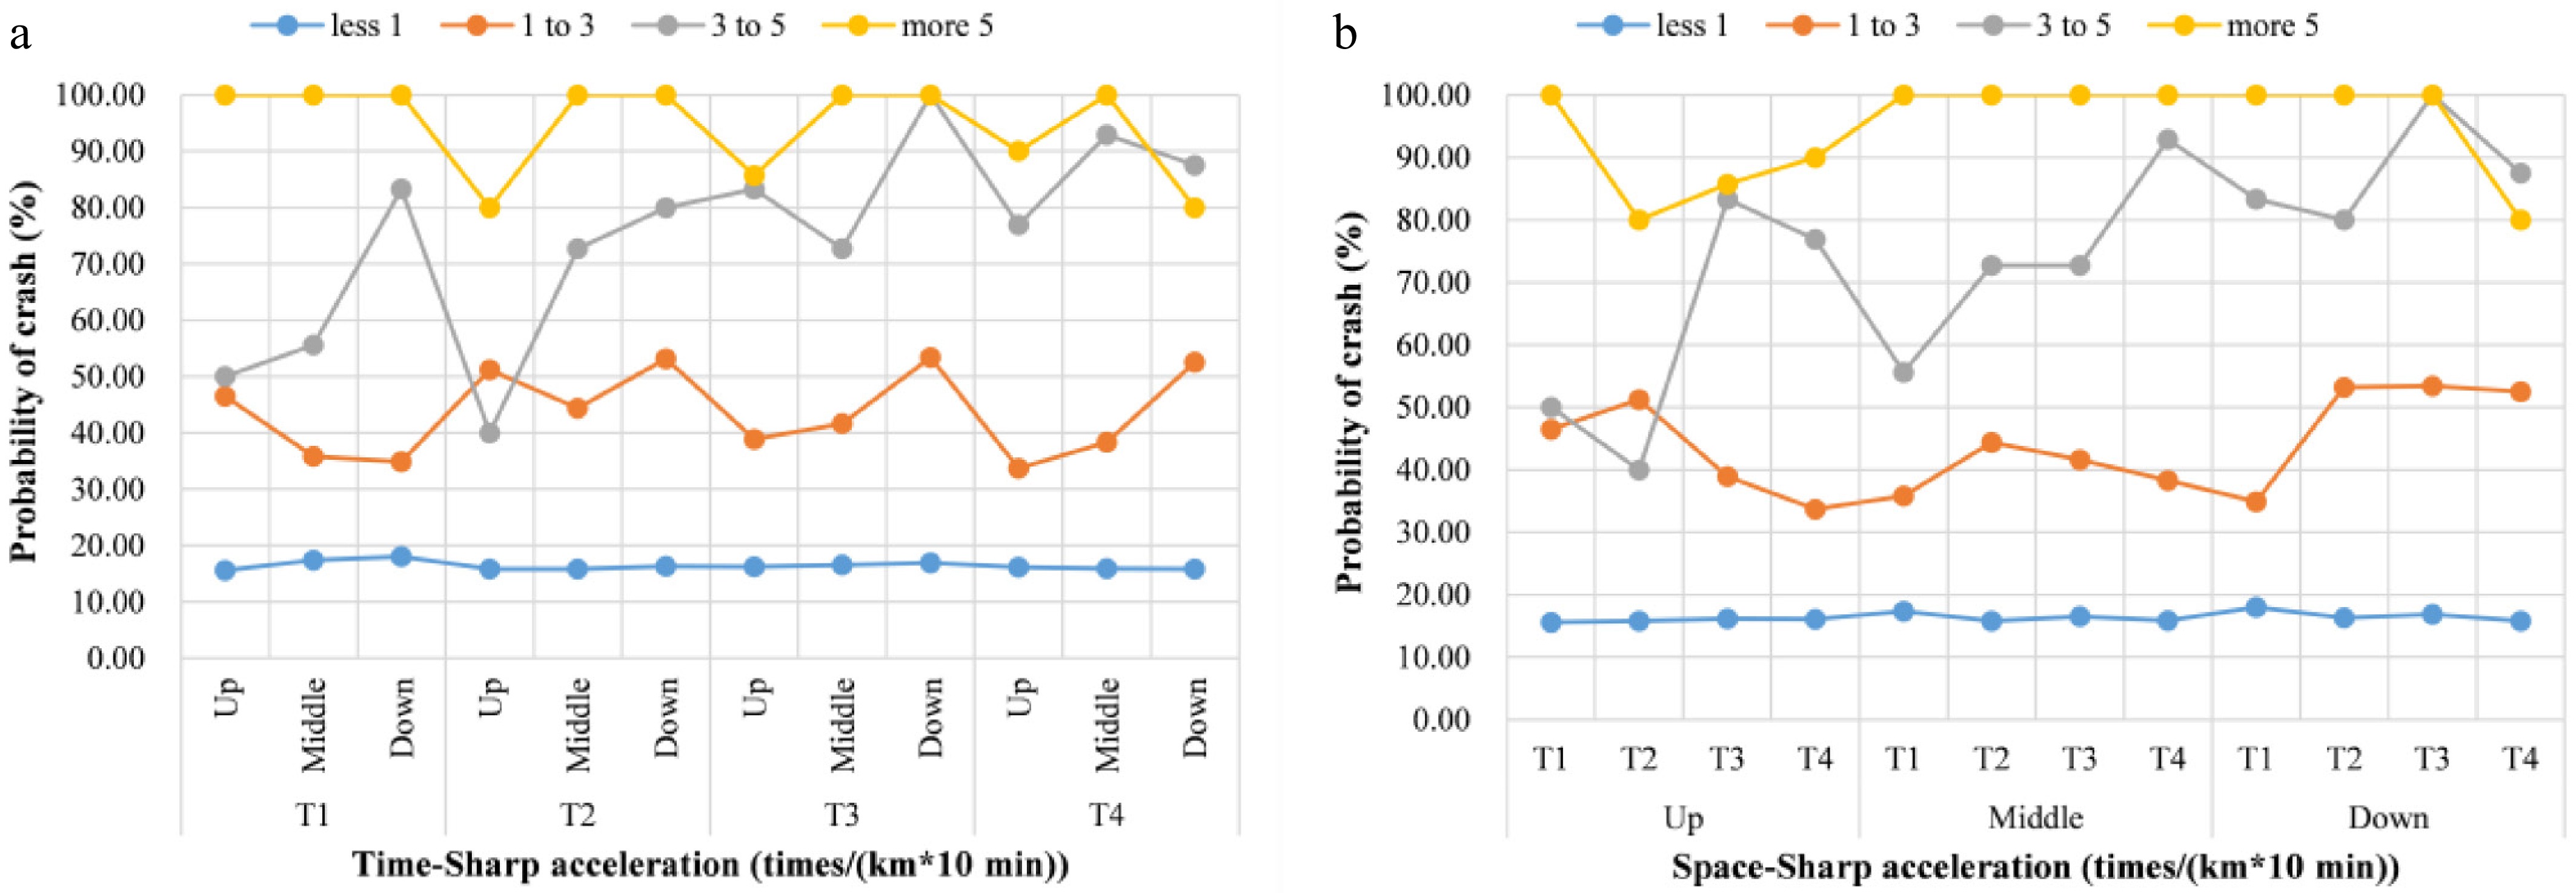
Figure 8.
Effect of a change in sharp acceleration on crash probability. (a) Temporal variation of sharp acceleration. (b) Spatial variation of sharp acceleration.
-
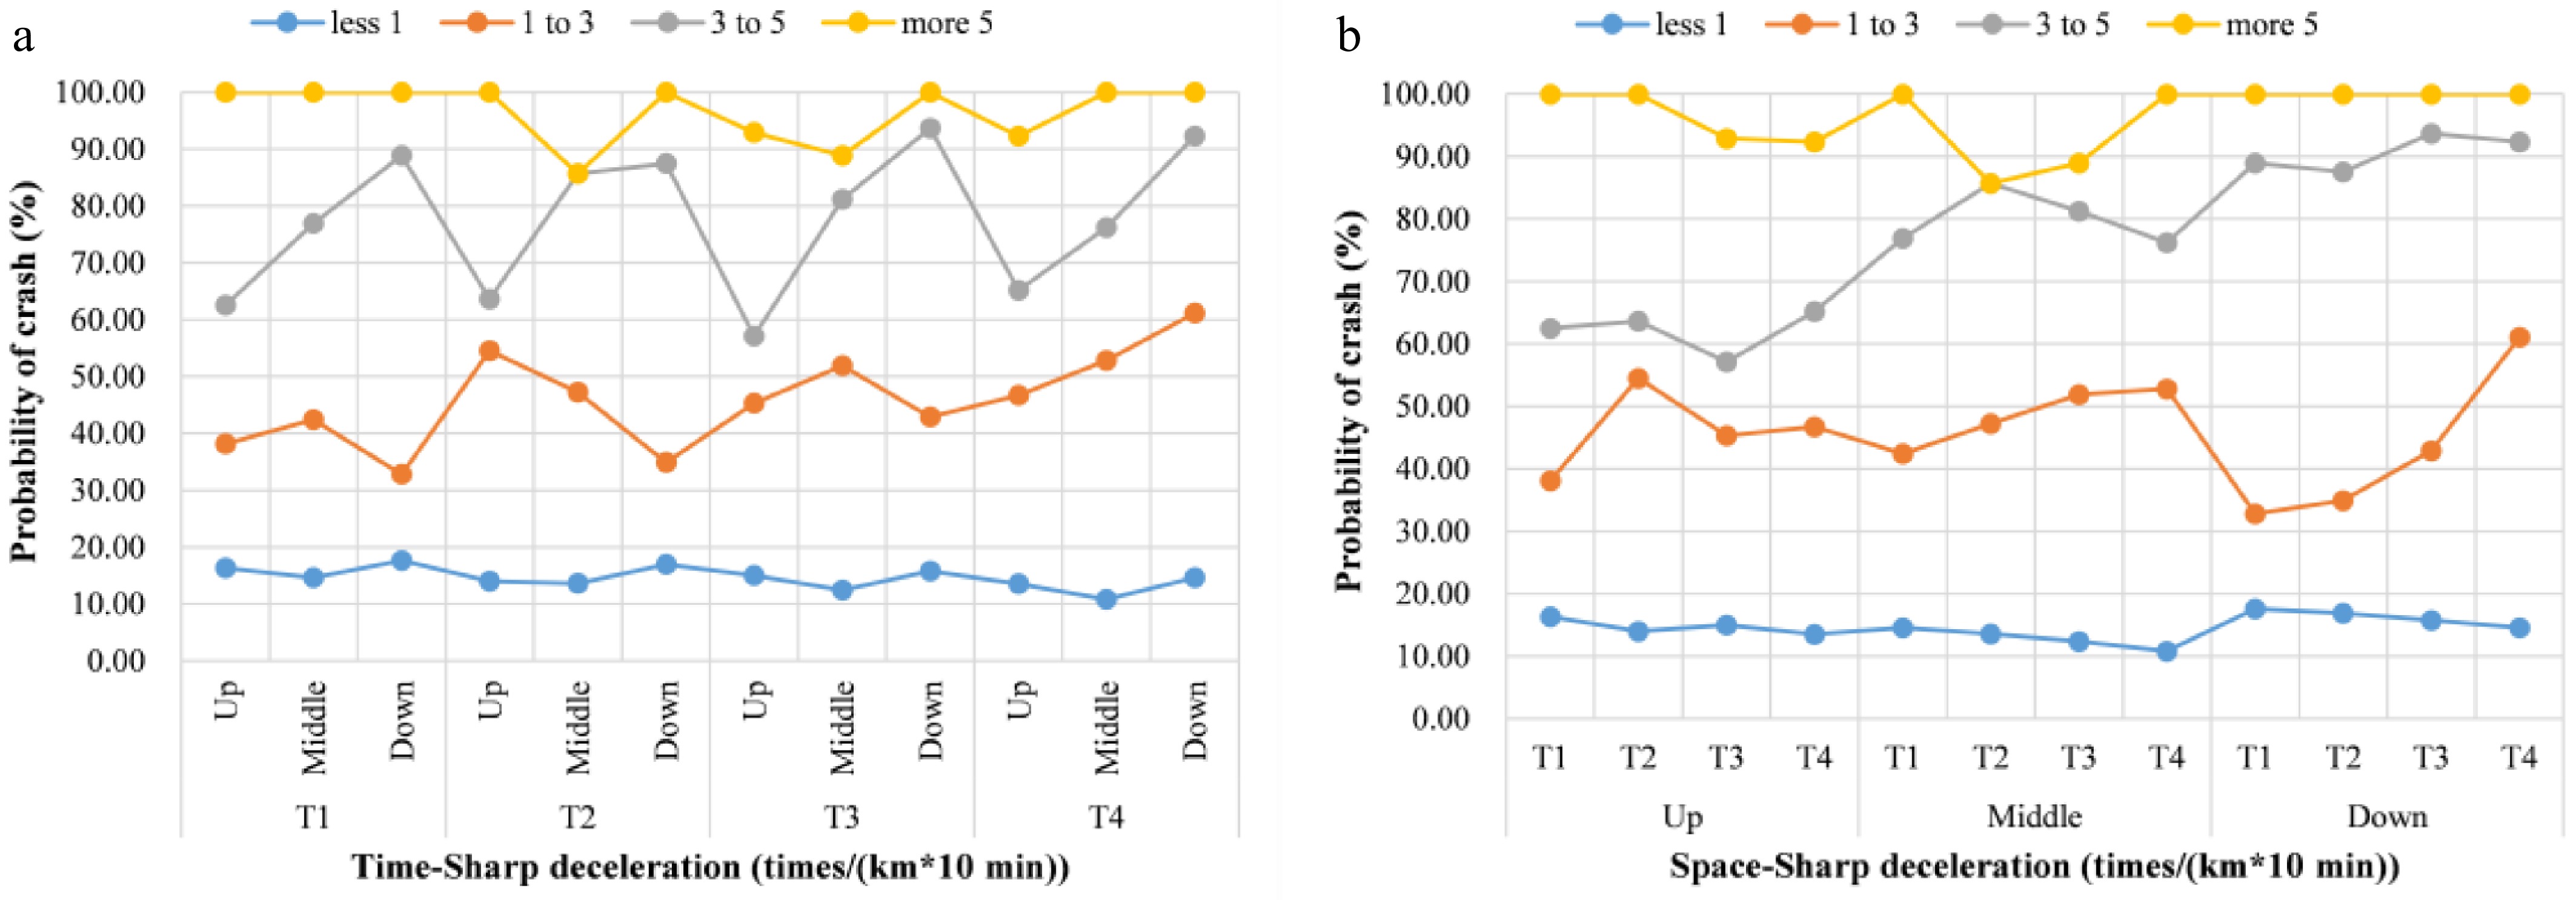
Figure 9.
Effect of a change in sharp deceleration on crash probability. (a) Temporal variation of sharp deceleration. (b) Spatial variation of sharp deceleration.
-
Data Description Time label Spatial label Data source Crash Collisions between vehicles on the road. 1 min 1 km (road segment) Freeway management department Volume The total number of vehicles passing a road point per unit time. 5 min 1 km (road point) Average speed The average speed of vehicles traveling a road segment per unit time. 10 min 1 km (road segment) In-vehicle navigation systems of mobile phones of vehicles driving on the freeway Congestion index Free-flow speed divided by the average road speed.1 Sharp acceleration If the linear acceleration was greater than a certain threshold, a sharp acceleration or deceleration would be recognized and recorded when the mobile phone was in a fixed position. 1 s Latitude and longitude Sharp deceleration Sharp left turn When a mobile phone was placed in a certain (fixed) position, the centripetal force of the original historical turn was measured. If the detection angle was greater than a certain threshold, it would be identified as a sharp merge into another lane or a sharp turn. Sharp right turn Sharp merge into the left lane Sharp merge into the right lane 1 The congestion index variable had four categories: the free-flow state (CI∈[0,1.5), slow-flow state (CI∈[1.5,2]), congestion state (CI∈[2,4]), and severe congestion state (CI∈[4, + ∞]). Table 1.
Details of the data.
-
Variables Mean Std Min. Max. Unit Volume 90.9512 55.5931 1.0000 384.0000 veh/10 min Average speed 77.4408 9.6283 2.3040 112.6440 km/h Congestion index 1.0809 0.4419 0.7600 33.8500 — Sharp acceleration 0.0022 0.0114 0.0000 2.0000 times/10 min Sharp deceleration 0.0020 0.0010 0.0000 1.0000 times/10 min Table 2.
Descriptive statistics of the dataset.
-
Abbr. Variables Categories Unit Frequency in crash (%) Frequency in non-crash (%) Vol. Volume Less 200 vehicles/
km·10 min9.43% 64.77% 200 to 400 74.20 32.51 400 to 600 16.24 2.69 More 600 0.12 0.03 A.S. Average speed Less 60 km/h 51.36 7.21 60 to 80 37.85 69.08 80 to 100 10.79 23.69 More 100 0.00 0.02 C.I. Congestion index 0 to 1.5 na 67.96 98.06 1.5 to 2 11.39 0.89 2 to 4 13.57 0.87 More 4 7.08 0.18 S.A. Sharp acceleration Less 1 times/
(km·10 min)72.03 92.74 1 to 3 21.26 6.94 3 to 5 4.22 0.28 More 5 2.50 0.04 S.D. Sharp deceleration less 1 times/
(km·10 min)63.11 92.25 1 to 3 24.45 7.26 3 to 5 6.86 0.44 More 5 5.58 0.05 Table 3.
The frequency distribution for each value range of variables.
-
Evaluation
indexOverall
accuracySensitivity False alarm
rateMissing report
rateResults 89.74% 88.24% 9.89% 11.76% Table 4.
The results of the dynamic Bayesian network evaluation.
Figures
(9)
Tables
(4)