



-
In recent years, frequent disasters have occurred worldwide. In disaster emergency response, rescue is the last defense to safeguard public life and property safety; for example, on November 26, 2025, a terrible fire broke out in Wang Fuk Yuen, Tai Po, Hong Kong, China, and a total of 391 fire engines were dispatched.
In general, dynamic rescue vehicle traffic operation on the road network is always related to multiple objectives consisting of traffic efficiency, traffic distance, and traffic distribution: traffic efficiency ensures a quicker arrival of rescue vehicles at the disaster position, traffic distance ensures a shorter travel distance of rescue vehicles to the disaster position, and traffic distribution ensures fewer roads are occupied by rescue vehicles. It is noted that there are objective conflicts and different impacts on social vehicle traffic in the rescue vehicle traffic optimization (RVTO) problem.
Taking the traffic network of Fig. 1 as an example, there are three traffic routes, A, B, and C, for the arrival of rescue vehicles from node 12 to node 1, and Table 1 defines their characteristics among traffic efficiency, traffic distance, and traffic distribution. Without loss of generality, we assume: Route A has the lowest traffic efficiency, the shortest traffic distance, and the least number of links; Route C has the highest traffic efficiency, the longest traffic distance, and the largest number of links; and Route B is at a medium level. Based on the requirements of 3T, which routes should be adopted by rescue vehicles? Moreover, when different traffic routes are adopted by rescue vehicles, rescue traffic operation interferes with social vehicle traffic operation. Therefore, the multi-objective combinatorial programming (MOCP)-RVTO problem should be focused on analyzing the coordination and importance of multiple conflict objectives and realizing their trade-off.
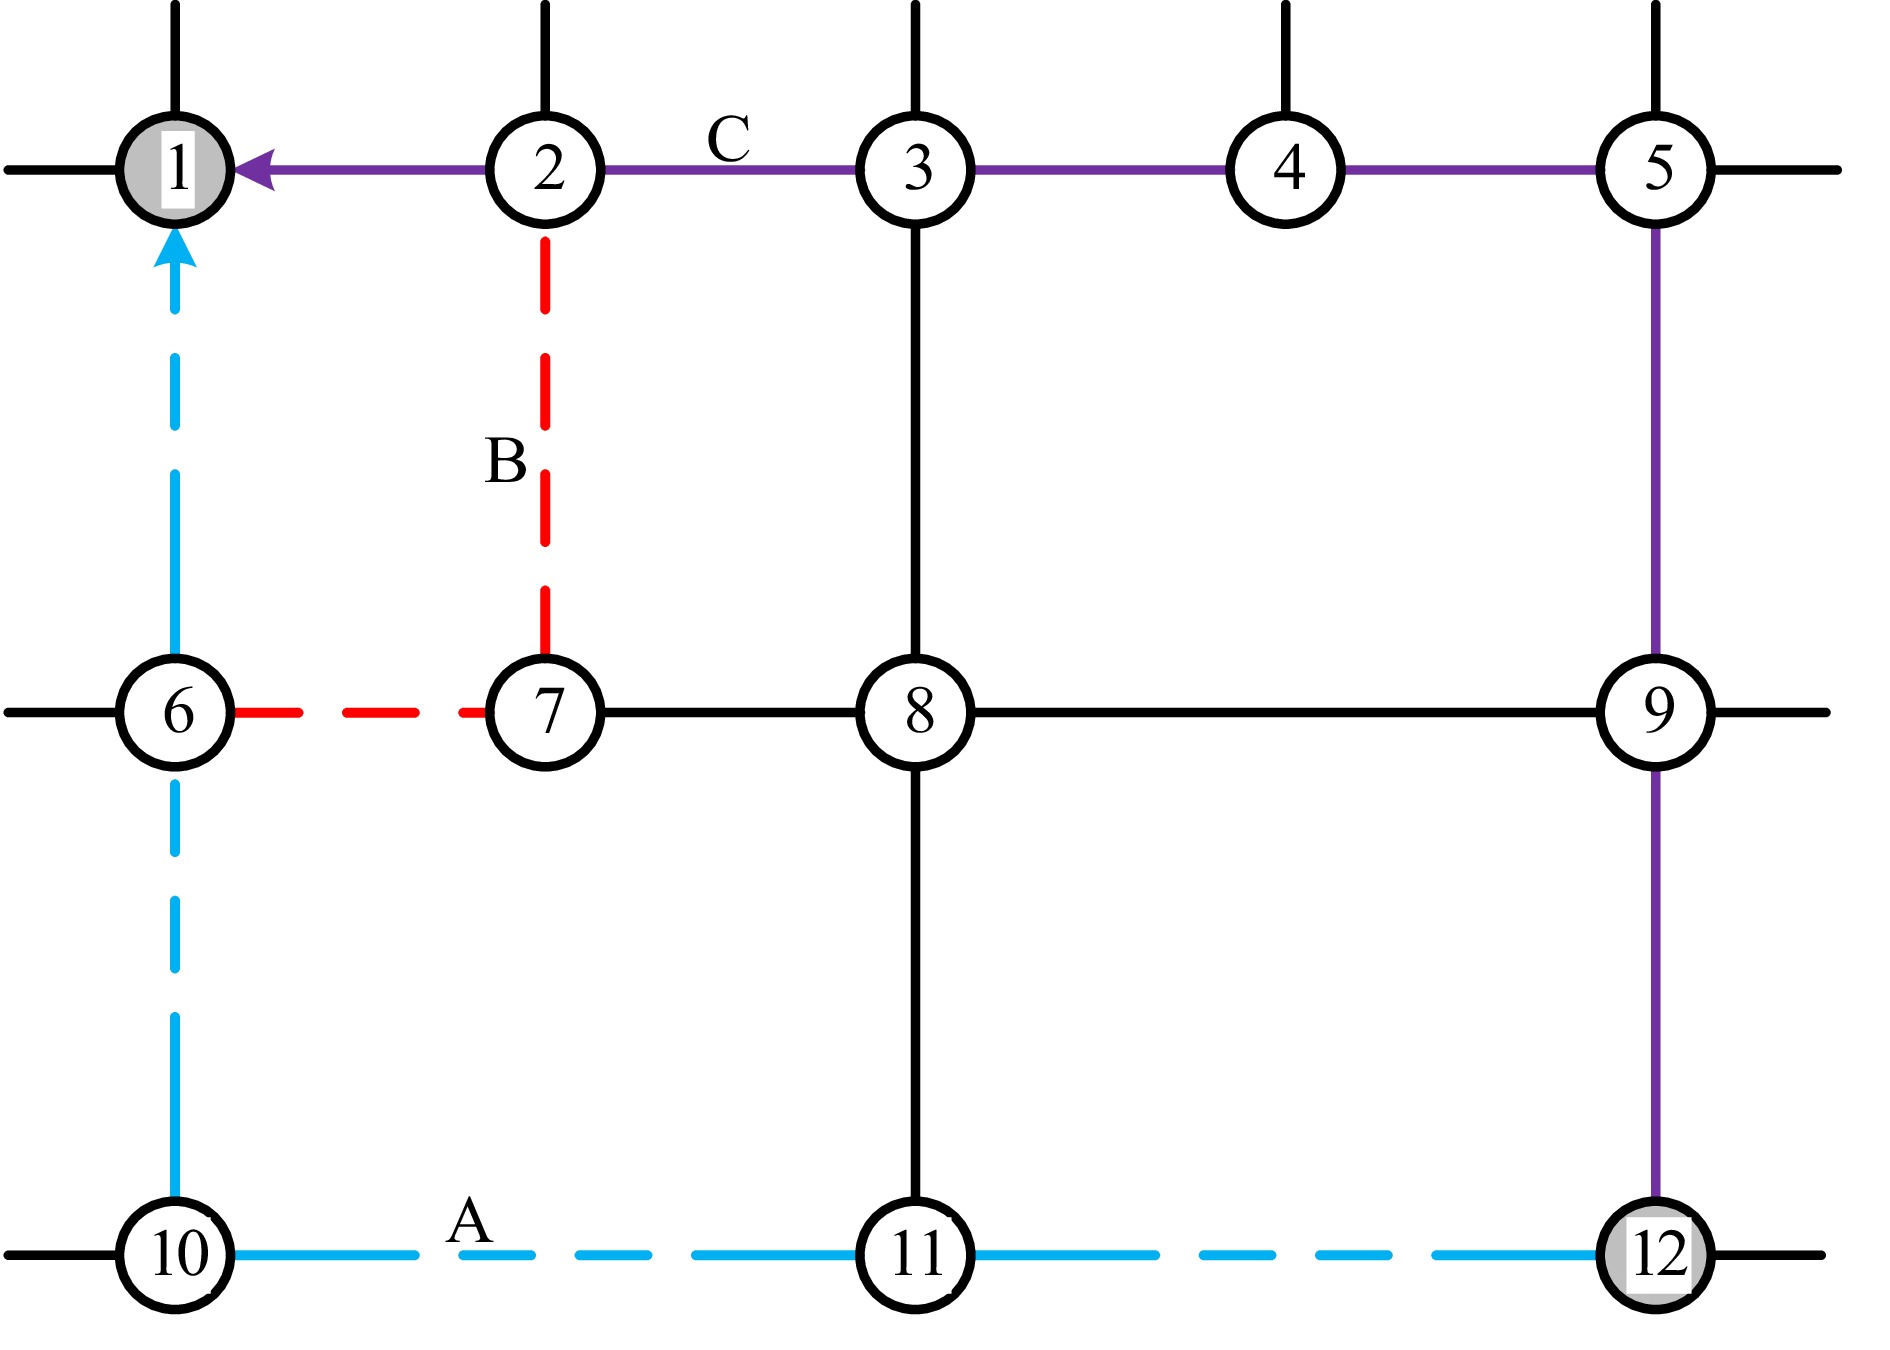
Figure 1.
MOCP-RVTO instruction on roads.
Table 1. Traffic route characteristics.
Objective index Route index A B C Traffic efficiency L M H Traffic distance L M H Traffic distribution L M H H, M, and L represent the high, medium, and low levels, respectively. In this paper, we evaluate multi-objective coordination and importance among traffic efficiency, traffic distance, and traffic distribution (3T) and analyze the impact of a dedicated rescue link opening restriction on social vehicle traffic operation by developing a MOCP-RVTO formulation and a multi-objective-weight evolutionary decomposition algorithm. Accordingly, the remainder of this paper is organized as follows: Literature review reviews and summarizes the current RVTO research status from the perspectives of vehicle class, road occupation, and solving approach; We develop a MOCP-RVTO formulation consisting of traffic efficiency, traffic distance, and traffic distribution, in which large-scale dynamic rescue vehicle traffic operation on the road network is described, and then, a multi-objective-weight evolutionary decomposition algorithm is designed by introducing objective weight decision variables and designing a genetic algorithm; At last, we present the numerical evaluation and analysis results tested on the Sioux-Falls road network, and conclude the MOCP-RVTO problem of considering social vehicle traffic.
-
As is well known, RVTO is a necessary step to improve large-scale rescue traffic network operation performance in disaster situations. In current research and practical applications, RVTO is often related to evacuation vehicle traffic operation, or social vehicle traffic operation on roads, and most of them mainly focus on multiclass evacuation and rescue traffic networks. In this regard, Chiu & Zheng[1] and Yang et al.[2] took weight evacuation and rescue traffic travel time minimization as an objective, and developed a single-objective mathematical programming model of evacuation and rescue traffic combinatorial optimization to solve dynamic evacuation and rescue traffic assignment on the road network; Kimms & Maassen[3] took the minimization of the number of evacuation vehicles traveling on roads as an objective, and developed a single-objective mixed integer linear programming model to discuss the combinatorial optimization problem of dynamic evacuation and rescue traffic network operation, with the aim of minimizing the weight value of evacuation cost, rescue cost, and traffic conflict; Cui et al.[4] developed a minimum cost flow model to optimize evacuation and rescue traffic allocation on a shared road network. Recently, Li et al.[5] aimed to minimize the total wait time for rescue of all victims and developed a single-objective mixed integer linear programming model to realize collaborative operational planning between post-disaster victim evacuation and relief distribution by considering heterogeneous rescue teams.
In addition to the above-mentioned single-objective evacuation and rescue vehicle traffic optimizations, there are also social vehicles on the rescue vehicle traffic network; however, social vehicles are usually regarded as background traffic, and rescue vehicles have traffic priority in traffic conflicts in current studies[6−10]. Moreover, only the obstruction of social traffic to rescue traffic is considered, but the impact of rescue traffic priority on social traffic is not considered on roads. Recently, given the development of intelligent and connected vehicle traffic technology in the field of disaster emergency rescue, on the basis of the existing studies of mixed traffic flow simulation and optimization of human-driven vehicles and automated vehicles[11−14], Liu & Pei[15] considered micro traffic behavior differences between manual and automated driving vehicles, and studied the mixed manual-automated driving rescue vehicle traffic route coordination optimization problem by introducing automated driving vehicle penetration rate decisions and developing a single-objective nonlinear mathematical programming model.
On the basis of single-objective multiclass vehicle emergency traffic optimization, some RVTO studies are also related to the MOCP problem; for example, Chen et al.[16] took the length of traffic routes of evacuation agents and rescue agents as two objectives to study two-way route planning for emergency rescue and emergency evacuation in a chemical industrial park; Liu et al.[17] developed a bi-objective mixed integer linear programming formulation of maximizing the number of rescue vehicles arriving at the disaster area within the different time and minimizing the number of the affected people stranded in the emergency area to realize evacuation and rescue traffic joint optimization. To maximize the number of rescue vehicles that have arrived in the disaster position by the end of the current time period and minimize the number of evacuation vehicles that have not arrived in the outside safe area, Liu et al.[18] developed a bi-objective evacuation and rescue traffic collaborative assignment optimization model to plan multiclass dynamic emergency traffic operation on roads. In this evacuation and rescue traffic MOCP example, every objective belongs to one specific vehicle class, and the rescue traffic optimization problem is modeled as a single-objective optimization model; thus, the classical stage-based decomposition solving approach is used, in which rescue traffic optimization is first solved without considering the evacuation process, and then evacuation traffic is optimized by reserving the optimal rescue traffic route. In addition, some studies also further focused on the impact of road time-space resource occupation scale (e.g., the number of the used intersection, the number of the used link, and the number of rescue contraflow link) of rescue vehicles on evacuation and rescue traffic optimization[19−22], however, the impact of reserving road time-space resource occupation scale to rescue vehicles on social vehicle traffic operation also should be further focused.
Overall, current RVTO studies have achieved numerous research findings in the field of single-objective and multi-objective evacuation and rescue traffic optimization, and single-objective rescue traffic optimization considering social vehicle background traffic. However, the multi-objective rescue vehicle traffic optimization problem and the impact of different objectives on social vehicle traffic have not been fully studied to improve emergency traffic network operation performance. In this paper, we try to solve the MOCP-RVTO problem and analyze the impact of multi-objective road time-space resource reserve on social vehicle traffic operation from the perspective of dedicated rescue link opening restriction. Here, we adopt the classical link transmission model (LTM) to describe the dynamic rescue traffic network loading process and use 3T as three objectives to coordinatively optimize rescue vehicle traffic routes on the road network, and then develop the MOCP-RVTO formulation. Moreover, we introduce three weight decision variables and optimal single-objective (SO) function values to weight RVTO objectives and transform the MOCP-RVTO formulation into an NLWSO-RVTO formulation, and further design a GAD-based solving approach to optimize objective weights and rescue vehicle traffic operation in stages. And last, the impact of dedicated rescue link opening restriction on social vehicle traffic operation is analyzed on the Paramics traffic simulation network, and the case is realized on the Sioux Falls example network.
The main highlights and contributions are as follows: (1) Multi-objective coordination among 3T is focused on by MOCP-RVTO, and their importance is analyzed by multiple objective weight optimization. (2) Rescue vehicle traffic route choice characteristics are analyzed based on SO-RVTO and NLWSO-RVTO by designing a GAD-based solving approach. (3) Interference of dedicated rescue link opening restriction on social vehicle traffic is analyzed based on different RVTO objectives.
-
The notations and definitions in Table 2 are adopted to mathematically describe the MOCP-RVTO problem on the dynamic rescue traffic network:
Table 2. Formulation notations and definitions.
Notations Definitions Sets $ L $ Set of links that constituting the rescue vehicle traffic network $ L' $ Set of links where rescue vehicles enter the disaster position from the road network, $ L'\subset L $ $ L'' $ Set of links where rescue vehicles enter the road network from the rescue station, $ L''\subset L $ $ S $ Set of rescue stations $ \Gamma _{i}^{+} $ Set of links that connect with link i in its downstream direction,$ i\in L,\Gamma _{i}^{+}\subset L $ $ \Gamma _{i}^{-} $ Set of links that connect with link i in its upstream direction,$ i\in L,\Gamma _{i}^{-}\subset L $ $ T $ Set of integer time periods that describe the dynamic rescue vehicle traffic network loading process Indices $ i,j $ Index of any link on the road network, $ i,j\in L $ $ t,\tau $ Index of any time period, $ t,\tau \in T $ $ s $ Index of any rescue station, $ s\in S $ $ o $ Index of the disaster position Parameters $ \alpha ,\delta $ Linear interpolation coefficient of cumulative traffic volume in non-integer time periods $ {d}_{s} $ Rescue traffic demand that represents the number of rescue vehicles called from rescue station$ s $, $ s\in S $ $ {l}_{i} $ Length of link i, $ i\in L $ $ {n}_{i} $ Number of lanes of link i, $ i\in L $ $ {Q}_{i} $ Road capacity, that is, the maximum number of rescue vehicles that can pass every lane of link i within any time period t, $ t\in T,i\in L $ $ \rho _{jam}^{(i)} $ Jam traffic density, that is, the maximum number of rescue vehicles that can be accommodated on every lane of link i, $ i\in L $ $ {\tau }_{i} $ Length of traffic free-flow time periods from upstream end to downstream on link i, $ i\in L $ $ {\iota }_{i} $ Length of backward traffic congestion shockwave propagation time periods from downstream end to upstream on link i, $ i\in L $ Variables $ U_{t}^{(i)} $ Cumulative number of rescue vehicles entering link i by the end of current time period t, $ t\in T,i\in L $ $ V_{t}^{(i)} $ Cumulative number of rescue vehicles leaving link i by the end of current time period t, $ t\in T,i\in L $ $ q_{t}^{(i,j)} $ Number of rescue vehicles entering link j from link i within current time period t, $ t\in T,i\in L,j\in \Gamma _{i}^{+} $ $ q_{t}^{(i,o)} $ Number of rescue vehicles arriving in the disaster position o from link i within current time period t, $ t\in T,i\in L' $ $ q_{t}^{(s,i)} $ Number of rescue vehicles entering link i from rescue station s within current time period t, $ t\in T,i\in L'',s\in S $ $ x_{t}^{(i)} $ Number of rescue vehicles on link i in the beginning of current time period t, $ t\in T,i\in L $ Multi-objective combinational modelling
-
We consider a collaborative optimization among traffic efficiency, traffic distance, and traffic distribution: traffic efficiency is modelled as Z1 to maximize the number of rescue vehicles arriving at the disaster position by the end of any time period; traffic distance is modelled as Z2 to minimize the travel distance of rescue vehicles from the rescue station to the disaster position; and traffic distribution is modelled as Z3 to minimize the number of links used by rescue vehicles.
$ {\mathrm{Max}}\;\; \text{Z1 =}{\sum }_{t\in T}{\sum}_{\tau =1}^{t}{\sum }_{i\in L'}q_{\tau }^{(i,o)} $ $ {\mathrm{Min}}\;\; \text{Z2}={\sum }_{i\in L}U_{|T|}^{(i)}{l}_{i} $ $ {\mathrm{Min}}\;\; \text{Z3}={\sum }_{i\in L}U_{|T|}^{(i)} $ Here, Z1 is equal to
$ \sum_{t=1}^{|T|}(|T|-t+1){\sum }_{i\in L'}q_{t}^{(i,o)} $ LTM-based dynamic rescue traffic network loading
-
Based on the classical LTM theory[23,24], we develop Eqs (1)–(4) to realize the dynamic loading process of large-scale rescue vehicle traffic on the road network by the relaxed LTM[17]:
$ V_{t}^{(i)}\leq U_{t-{\tau }_{i}}^{(i)}\;\;t\in T,i\in L $ (1) $ V_{t}^{(i)}-V_{t-1}^{(i)}\leq {n}_{i}{Q}_{i}\;\;t\in T,i\in L $ (2) $ U_{t}^{(i)}\leq V_{t-{\iota }_{i}}^{(i)}+{n}_{i}{l}_{i}\rho _{jam}^{(i)}\;\;t\in T,i\in L $ (3) $ U_{t}^{(i)}-U_{t-1}^{(i)}\leq {n}_{i}{Q}_{i}\;\;t\in T,i\in L $ (4) here, Eq. (1) describes the cumulative number of rescue vehicles that leave link i by the end of time period t is less than or equal to the cumulative number of rescue vehicles that enter link i by the end of time period
$ t-{\tau }_{i} $ In Eqs (1)–(4), the cumulative inflow and outflow numbers of rescue vehicles that enter and leave link i also need to be obtained by the end of the non-integer time period. Here, based on the linear interpolation method, we introduce the interpolation coefficient α to calculate the cumulative inflow number of rescue vehicles in Eq. (5), and introduce the interpolation coefficient δ to calculate the cumulative outflow number of rescue vehicles in Eq. (6).
$ U_{t+\alpha }^{(i)}=(1-\alpha )U_{t}^{(i)}+\alpha U_{t+1}^{(i)}t\in T,i\in L,\alpha \in [0,1] $ (5) $ V_{t+\delta }^{(i)}=\left\{\begin{aligned} &(1-\delta )V_{t}^{(i)}t=\left\lfloor {\tau }_{i}\right\rfloor ,&&0\leq \delta \leq {\tau }_{i}-\left\lfloor {\tau }_{i}\right\rfloor &\\ &\dfrac{\delta -({\tau }_{i}-\left\lfloor {\tau }_{i}\right\rfloor )}{1-({\tau }_{i}-\left\lfloor {\tau }_{i}\right\rfloor )}V_{t+1}^{(i)} &&t=\left\lfloor {\tau }_{i}\right\rfloor ,{\tau }_{i}-\left\lfloor {\tau }_{i}\right\rfloor \leq \delta \leq 1&\\ &(1-\delta )V_{t}^{(i)}+\delta V_{t+1}^{(i)} &&t\in T \{\left\lfloor {\tau }_{i}\right\rfloor \},0\leq \delta \leq 1& \end{aligned}\right. i\in L $ (6) In addition, Eq. (7) is adopted to optimize the number of rescue vehicles that enter link i from its upstream adjacent links and the rescue station within time period t; Eq. (8) is adopted to optimize the number of rescue vehicles that enter its downstream adjacent links and arrive in the disaster position from link i within time period t.
$ U_{t}^{(i)}-U_{t-1}^{(i)}={\sum }_{j\in {{\Gamma }^-}}q_{t}^{(j,i)}+{\sum }_{s\in S}q_{t}^{(s,i)}t\in T,i\in L $ (7) $ V_{t}^{(i)}-V_{t-1}^{(i)}={\sum }_{j\in {{\Gamma }^+}}q_{t}^{(i,j)}+q_{t}^{(i,o)}t\in T,i\in L $ (8) In the traffic conservation equation of Eq. (9), the number of rescue vehicles on link i in the beginning of time period t + 1 should be equal to the number of rescue vehicles on link i in the beginning of time period t, plus the number of rescue vehicles that enter link i from its upstream adjacent links and the rescue station within time period t, and then minus the number of rescue vehicles that enter its downstream adjacent links and arrive in the disaster position from link i within time period t.
$ x_{t+1}^{(i)}=x_{t}^{(i)}+\left({\sum }_{j\in {{\Gamma }^-}}q_{t}^{(j,i)}+{\sum }_{s\in S}q_{t}^{(s,i)}\right)-\left({\sum }_{j\in {{\Gamma }^+}}q_{t}^{(i,j)}+q_{t}^{(i,o)}\right)t\in T,i\in L $ (9) When rescue vehicles travel on roads, they originate from the outside rescue stations and finally arrive at the disaster position. Therefore, the dynamic network loading of rescue vehicles should obey traffic generation and attraction balance, that is, all called rescue vehicles should enter the disaster position from the rescue station. Here, traffic generation of rescue vehicles from the rescue station can be mathematically expressed as Eq. (10), and traffic attraction of rescue vehicles in the disaster position can be mathematically expressed as Eq. (11):
$ {d}_{s}={\sum }_{i\in {{L}^{''}}}{\sum }_{t\in T}q_{t}^{(s,i)}s\in S $ (10) $ {\sum }_{i\in L'}{\sum }_{t\in T}q_{t}^{(i,o)}={\sum }_{s\in S}{\sum }_{i\in {{L}^{''}}}{\sum }_{t\in T}q_{t}^{(s,i)} $ (11) Last, Eqs (12) and (14) are presented to describe that there are no rescue vehicles on roads before the disaster occurs. Equation (13) describes that no rescue vehicles leave the links under the restriction of their traffic-free-flow time period. Equation (15) is the non-negative constraint:
$ U_{0}^{(i)}=0\;\;i\in L $ (12) $ V_{t}^{(i)}=0\;\;t\in \{0,1,\cdots ,\left\lfloor {\tau }_{i}\right\rfloor \},i\in L $ (13) $ x_{0}^{(i)}=0\;\;i\in L $ (14) $ x_{t}^{(i)}\geq 0,q_{t}^{(i,j)}\geq 0,q_{t}^{(i,o)}\geq 0,q_{t}^{(s,i)}\geq 0\;\;i\in L,j\in \Gamma _{i}^+,s\in S $ (15) -
In this section, the focused RVTO problem is a multi-objective combinatorial programming problem. As shown in Fig. 2, we design a GAD-based solving approach to realize their coordination and trade-off. Here, the GAD-based solving approach has some advantages in addressing the focused MOCP-RVTO problem. First, every objective is optimized independently to ensure the GAD-based solving approach can obtain a better solution of realizing all objectives as much as possible. Second, before solving the MOCP-RVTO problem, the weight coefficient of every objective can be optimized based on a genetic algorithm to reduce the solving complexity of the MOCP-RVTO problem. Third, based on the heuristic weight coefficient values, the optimal objective function value and rescue vehicle traffic operation plans can be obtained.
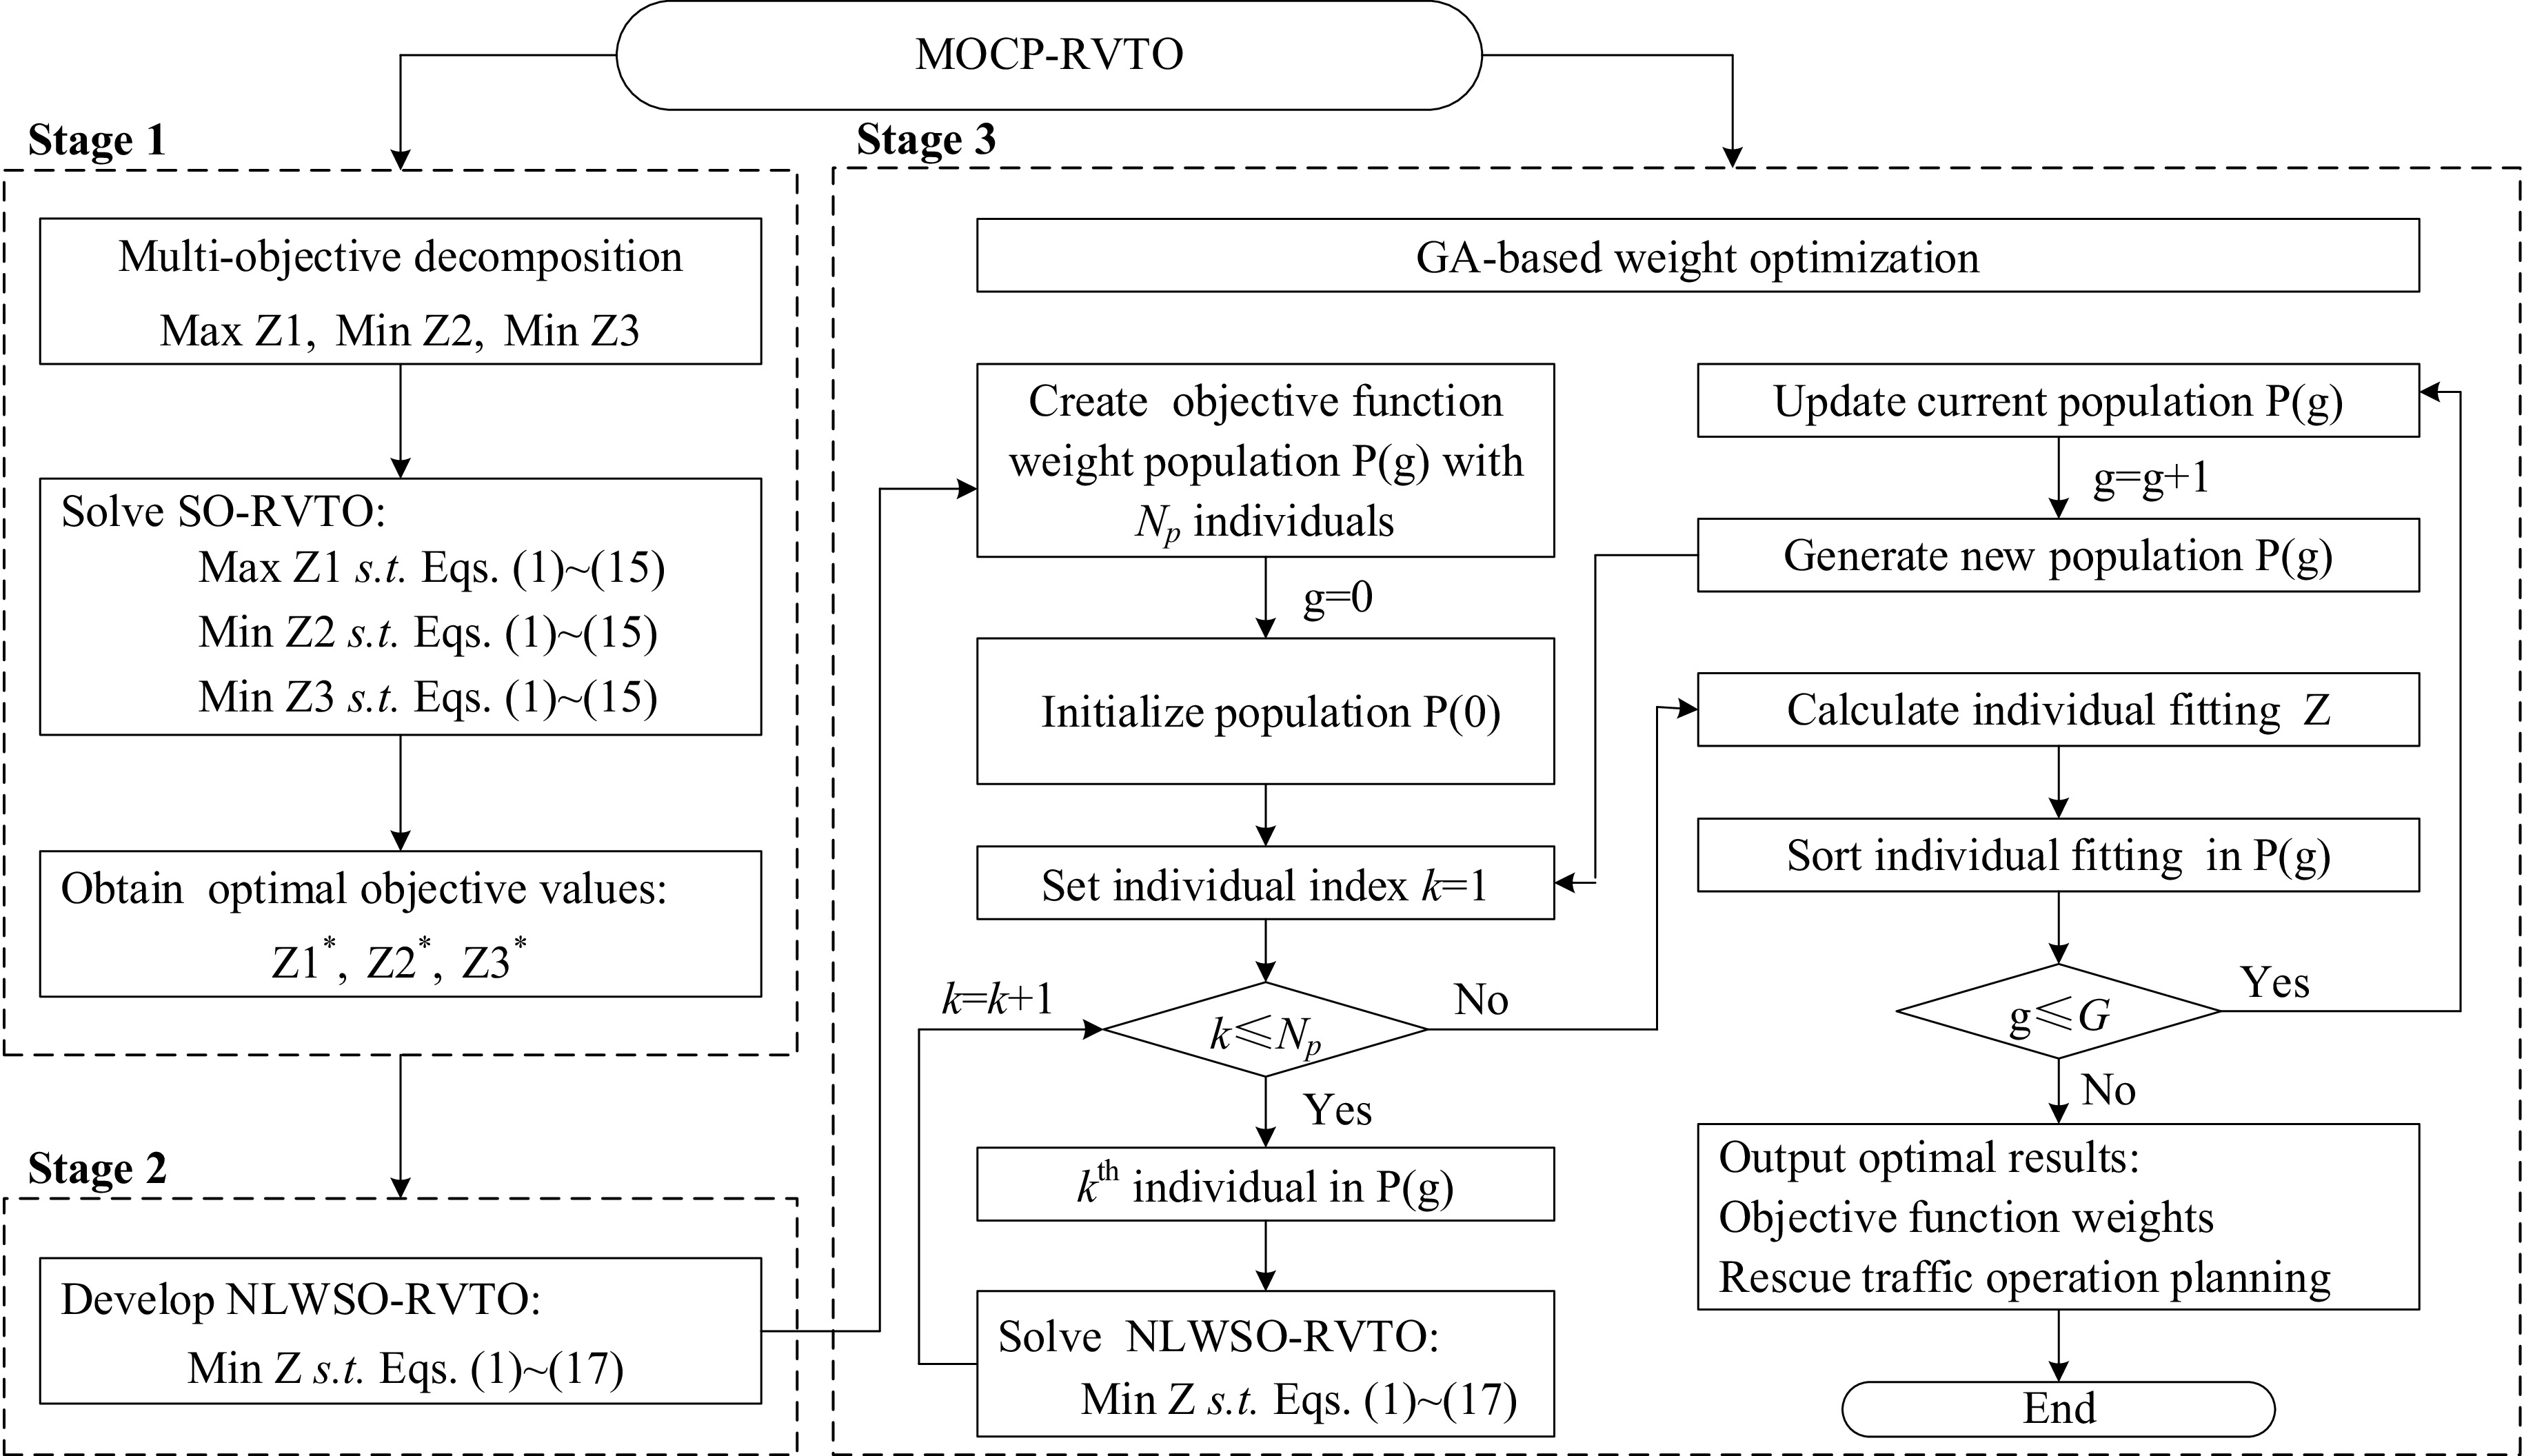
Figure 2.
GAD-based MOCP-RVTO solving approach execution flow diagram.
Stage 1: Decompose MOCP-RVTO as single-objective optimization
-
Decompose MOCP formulation subjected to Eqs (1)–(15) as three independent single-objective optimization formulations: max Z1 subjected to Eqs (1)–(15), min Z2 subjected to Eqs (1)–(15), min Z3 subjected to Eqs (1)–(15), and then obtain the optimal value Z1*, Z2*, Z3* of the objective functions Z1, Z2, Z3.
Stage 2: Develop NLWSO-RVTO formulation
-
Normalize the objective function Z1, Z2, and Z3 as Z1/Z1*, Z2/ Z2*, and Z3/Z3*, and weight them as '−a1 × Z1/Z1* + a2 × Z2/Z2* + a3 × Z3/Z3*' by introducing weight coefficient decision variables a1, a2, and a3; then, develop the NLWSO-RVTO formulation as min Z subjected to Eqs (1)–(17).
$ \min \text{Z=}-{\text{a}}_{1}\dfrac{\text{Z1}}{{\text{Z1}}^{*}}+{\text{a}}_{2}\dfrac{\text{Z2}}{{\text{Z2}}^{*}}+{\text{a}}_{3}\dfrac{\text{Z3}}{{\text{Z3}}^{*}} $ s.t.
$ {\text{a}}_{1}+{\text{a}}_{2}+{\text{a}}_{3}=1 $ (16) $ {0 \lt {\text{a}}}_{1},{\text{a}}_{2},{\text{a}}_{3} \lt 1 $ (17) $ {\mathrm{Equations}}\;(1)-(15)$ Stage 3: Solving NLWSO-RVTO formulation
-
Adopt genetic algorithm to optimize weight coefficients a1, a2, a3 in advance, and then solve min Z subjected to Eqs (1)–(17) to obtain the optimal function value and rescue vehicle traffic operation plans.
-
As shown in Fig. 3, the numerical analysis of the GAD-based MOCP-RVTO problem is presented on a Sioux Falls road network. Here, the nodes represent the intersections, the links between adjacent nodes represent the roads, and the length of every link and the number of its lanes are described by the traffic network attribute Table 3. We assume the rescue station is located near node 15 and rescue vehicles can enter the road network by node 15. The disaster position is located near node 1, and rescue vehicles can arrive at the disaster position by node 1 from the road network. In addition, in terms of the traffic parameter setting, eight rescue traffic demands, consisting of 30, 60, 90, 120, 150, 180, 210, and 240 rescue vehicles are tested, traffic free-flow speed is 72 km/h, backward traffic congestion shockwave propagation speed is 18 km/h on roads, traffic density is 150 vehicles/km/lane on roads, and road capacity is 2,160 vehicles/h/lane. In terms of GAD parameter settings, crossover probability is 0.8, mutation probability is 0.1, maximum evolutionary algebra (G) is 500, and every population consists of eight individuals.
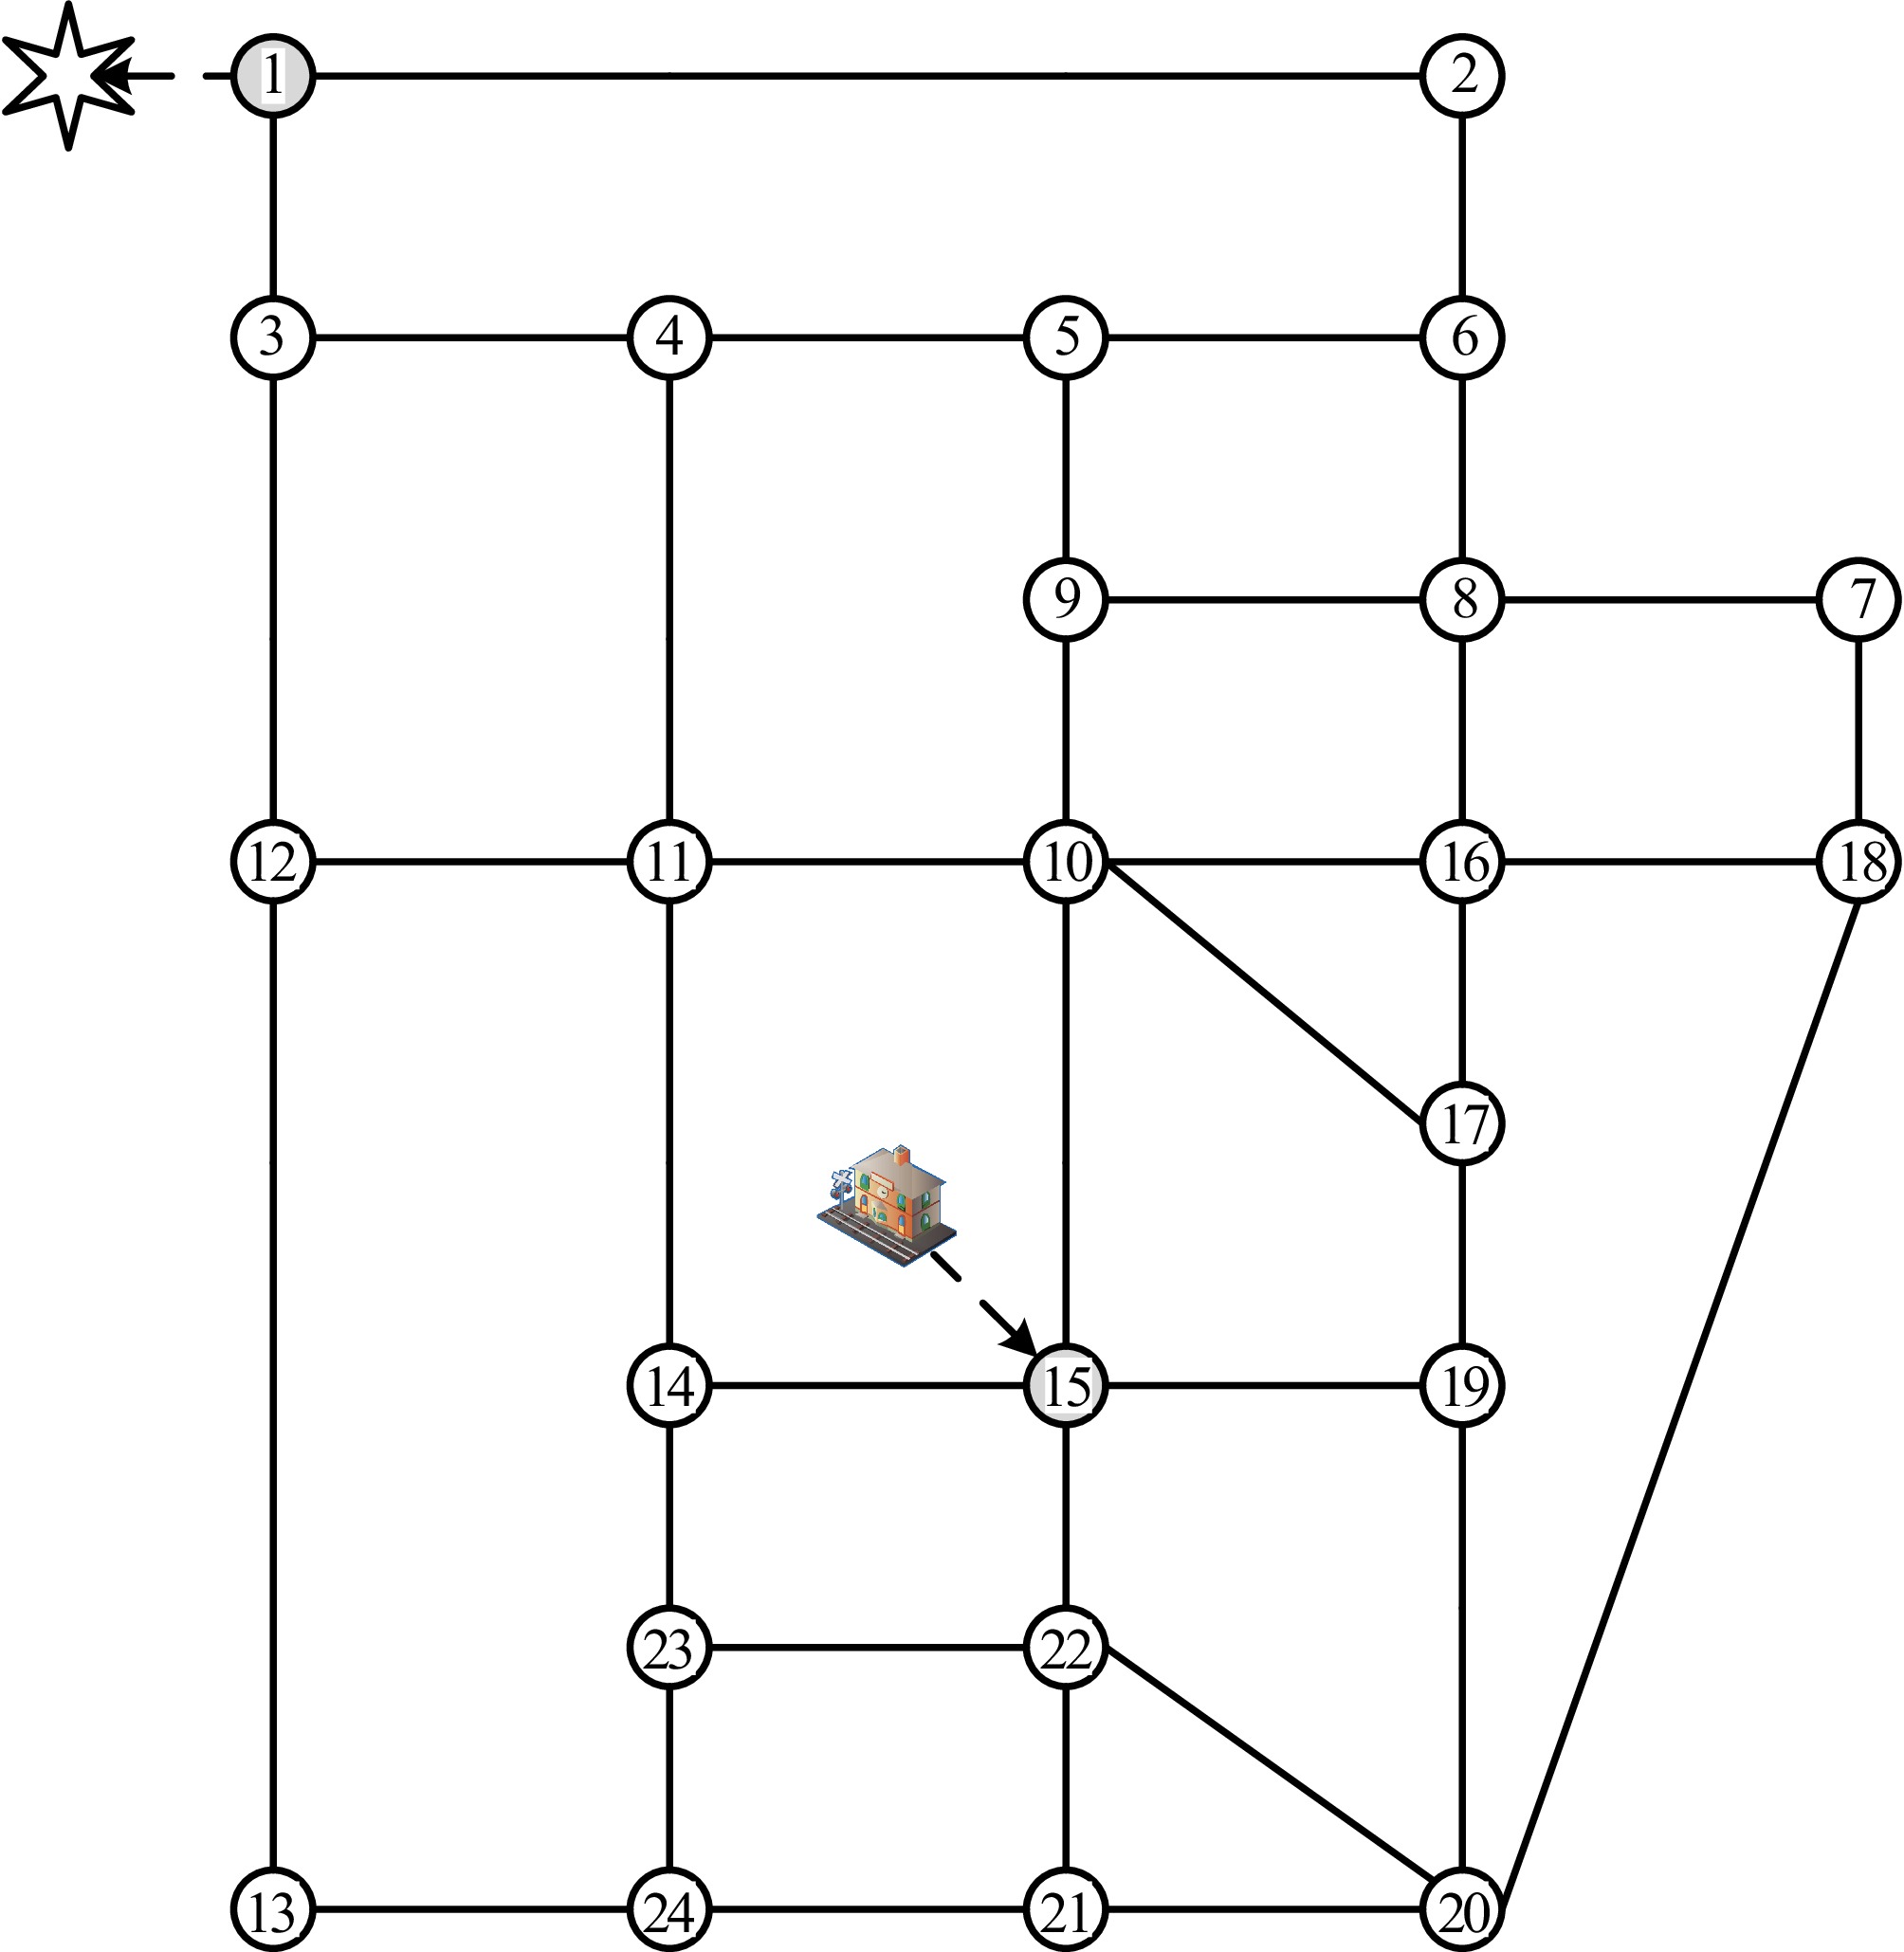
Figure 3.
Sioux Falls example network structure.
Table 3. Traffic network attributes.
Link index Node series Lanes Length (m) Link index Node index Lanes Length (m) Link index Node index Lanes Length (m) 1 1→2 4 900 27 10→11 2 300 53 17→19 1 200 2 1→3 4 200 28 10→15 2 400 54 18→7 4 200 3 2→1 2 900 29 10→16 1 300 55 18→16 3 300 4 2→6 1 200 30 10→17 1 360 56 18→20 4 855 5 3→1 2 200 31 11→4 1 400 57 19→15 3 300 6 3→4 3 300 32 11→10 2 300 58 19→17 1 200 7 3→12 4 400 33 11→12 1 300 59 19→20 1 400 8 4→3 3 300 34 11→14 1 400 60 20→18 4 855 9 4→5 3 300 35 12→3 4 400 61 20→19 1 400 10 4→11 1 400 36 12→11 1 300 62 20→21 1 300 11 5→4 3 300 37 12→13 4 800 63 20→22 1 360 12 5→6 1 300 38 13→12 4 800 64 21→20 1 300 13 5→9 2 200 39 13→24 1 300 65 21→22 1 200 14 6→2 1 200 40 14→11 1 400 66 21→24 1 300 15 6→5 1 300 41 15→14 1 300 67 22→15 2 200 16 6→8 1 200 42 14→23 1 200 68 22→20 1 360 17 7→8 1 300 43 15→10 2 400 69 22→21 1 200 18 7→18 4 200 44 14→15 1 300 70 23→22 1 300 19 8→6 1 200 45 15→19 3 300 71 23→14 1 200 20 8→7 1 300 46 15→22 2 200 72 22→23 1 300 21 8→9 1 300 47 16→8 1 200 73 23→24 1 200 22 8→16 1 200 48 16→10 1 300 74 24→13 1 300 23 9→5 2 200 49 16→17 1 200 75 24→21 1 300 24 9→8 1 300 50 16→18 3 300 76 24→23 1 200 25 9→10 2 200 51 17→10 1 360 26 10→9 2 200 52 17→16 1 200 Multi-objective optimization performance analysis
-
Considering the trend similarity of fitting curves among rescue traffic demands of 30, 60, 90, 120, 150, 180, 210, and 240, Fig. 4 takes rescue traffic demands of 60, 120, 180, and 240 as examples to present the GAD-based Z-value fitting curves. As shown in Fig. 4, the values of the objective function Z show almost no drop from the 200th iteration to the 500th iteration, and the trend means the GAD-based solving approach can achieve better convergence to the NLWSO-RTVO formulation of the MOCP-RVTO problem.
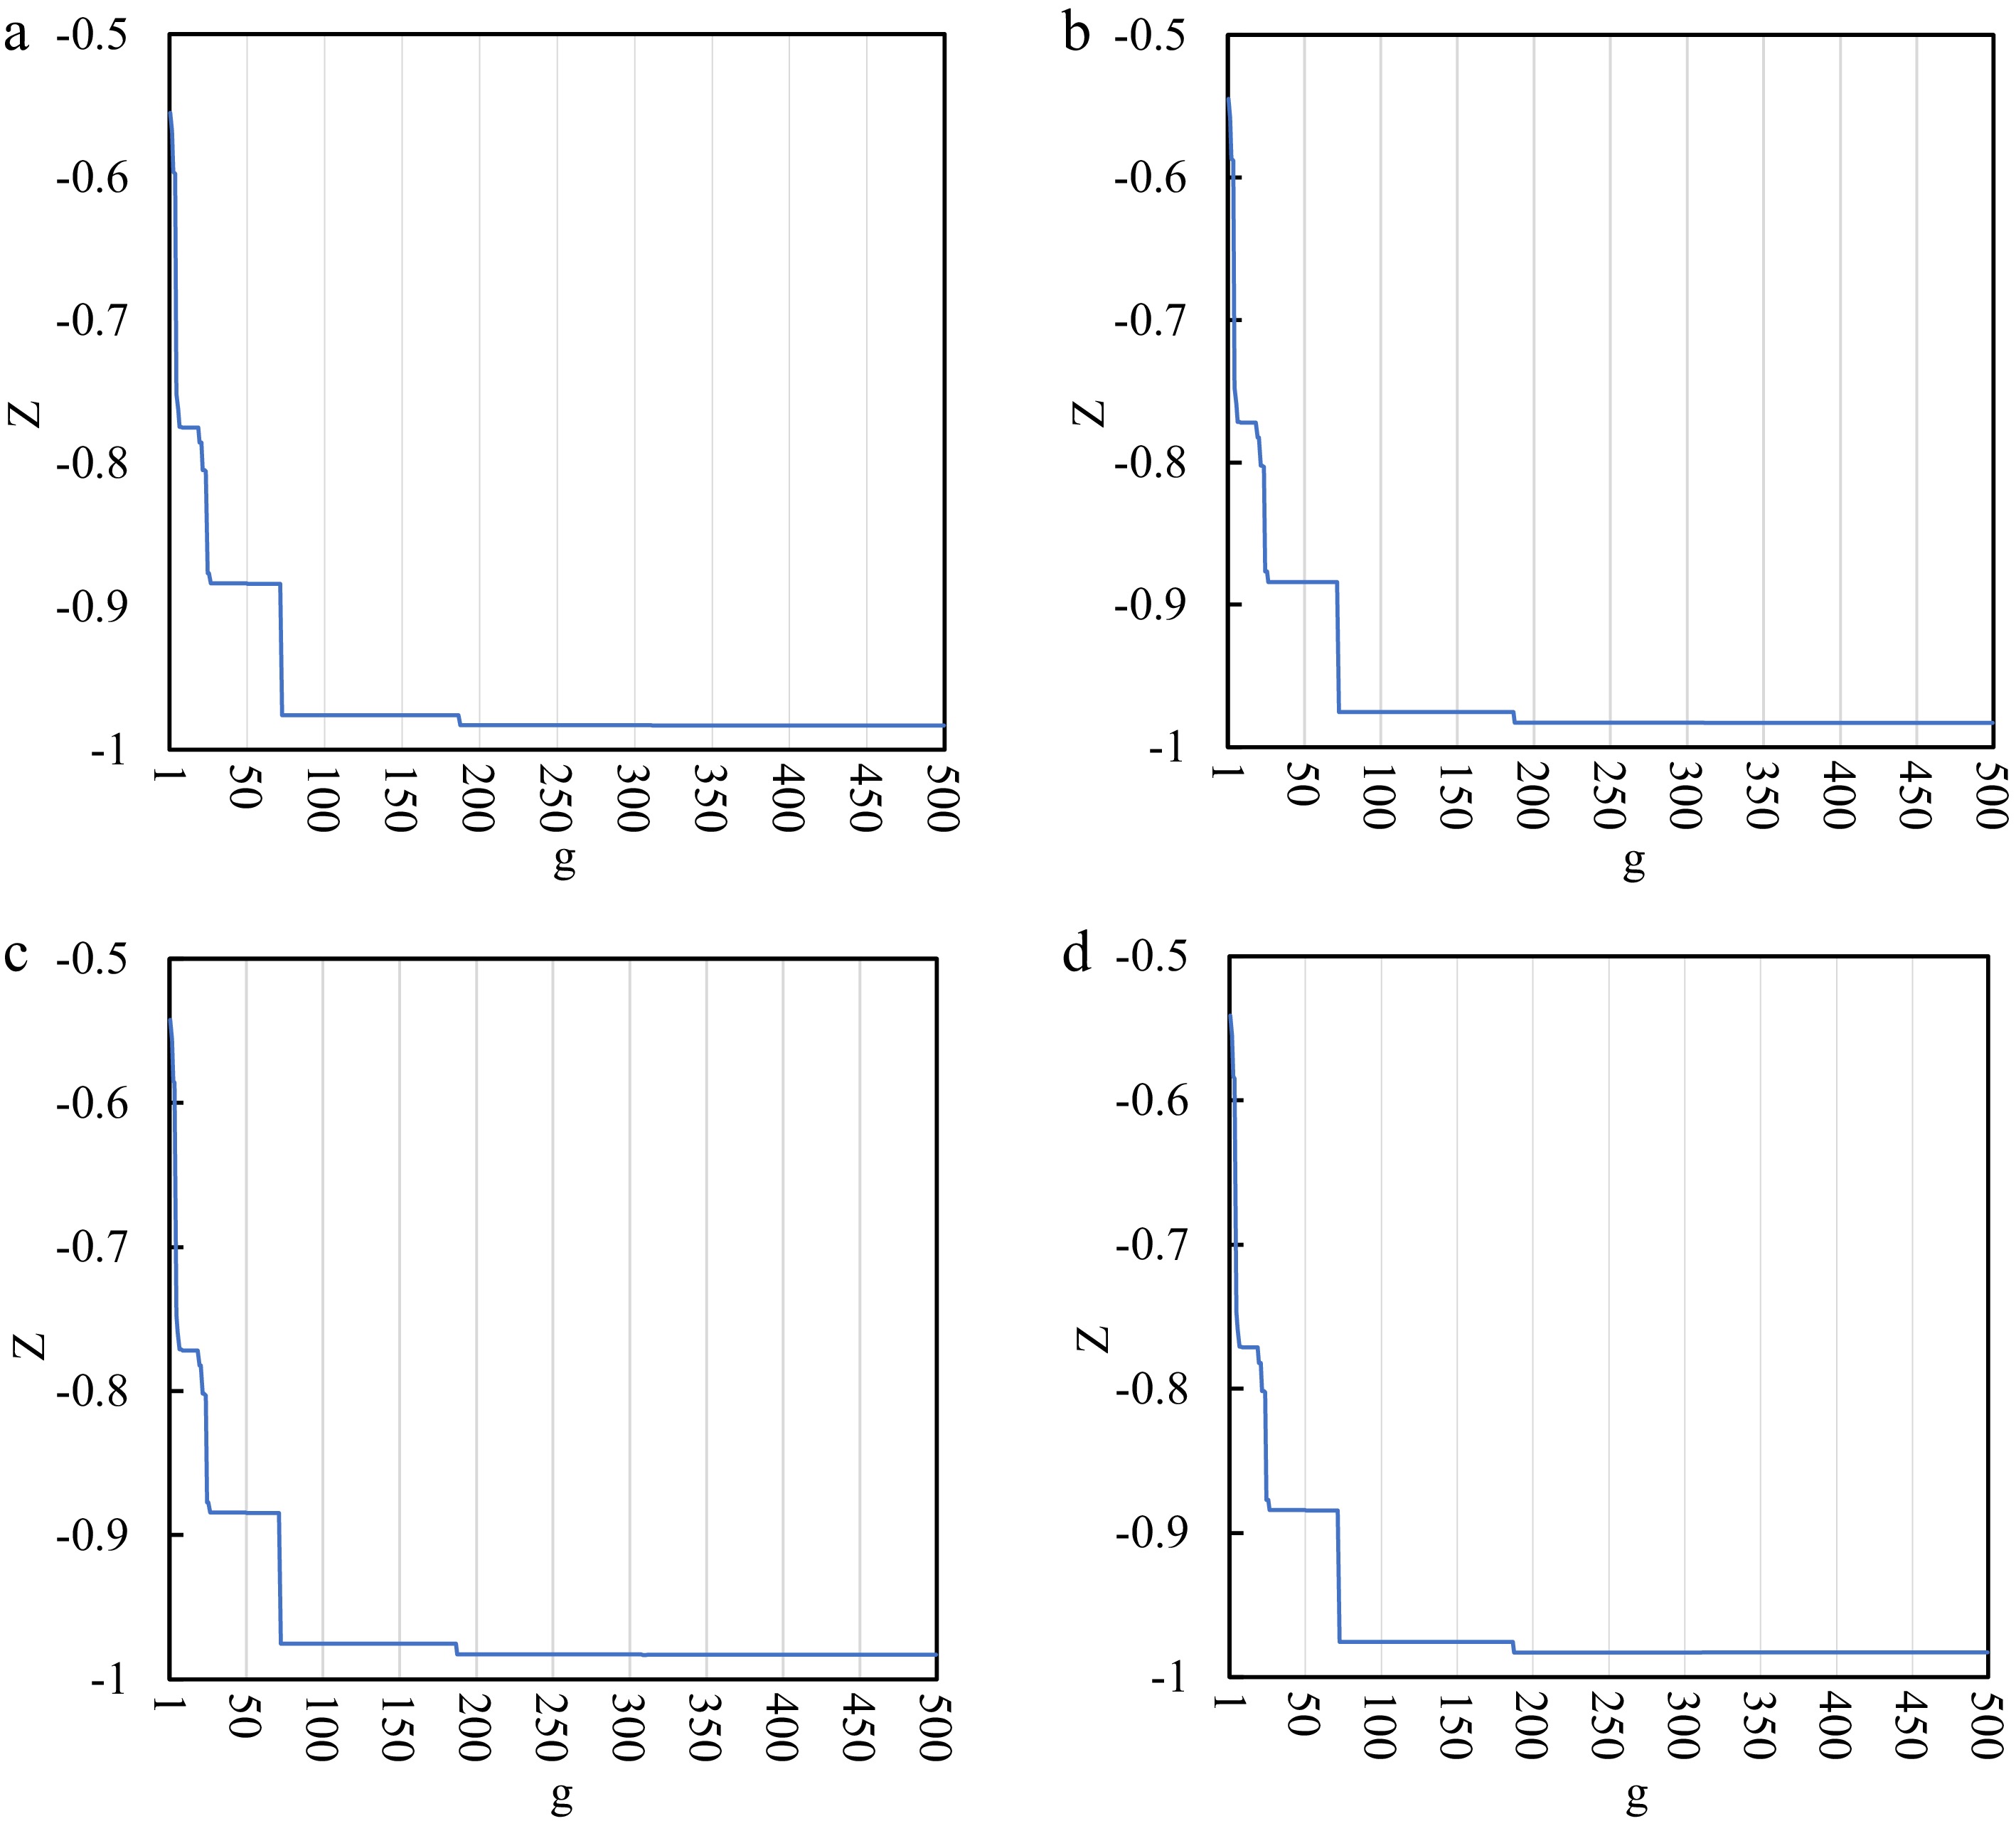
Figure 4.
Z-based fitting curves. (a) ds = 60. (b) ds = 120. (c) ds = 180. (d) ds = 240.
In Fig. 5, we input four independent solving results of max Z1 subjected to Eqs (1)–(15), min Z2 subjected to Eqs (1)–(15), min Z3 subjected to Eqs (1)–(15), and min Z subjected to Eqs (1)–(17) into three objective functions of Z1, Z2, and Z3, present the values of Z1, Z2, and Z3, and give the number of links used by rescue vehicles. Here, |L| is the number of links used by rescue vehicles; the unit of Z1 value is 100, the unit of Z2 value is 10,000, the unit of Z3 value is also 100, and the unit of |L| value is 1; moreover, every value is rounded to four decimal places.
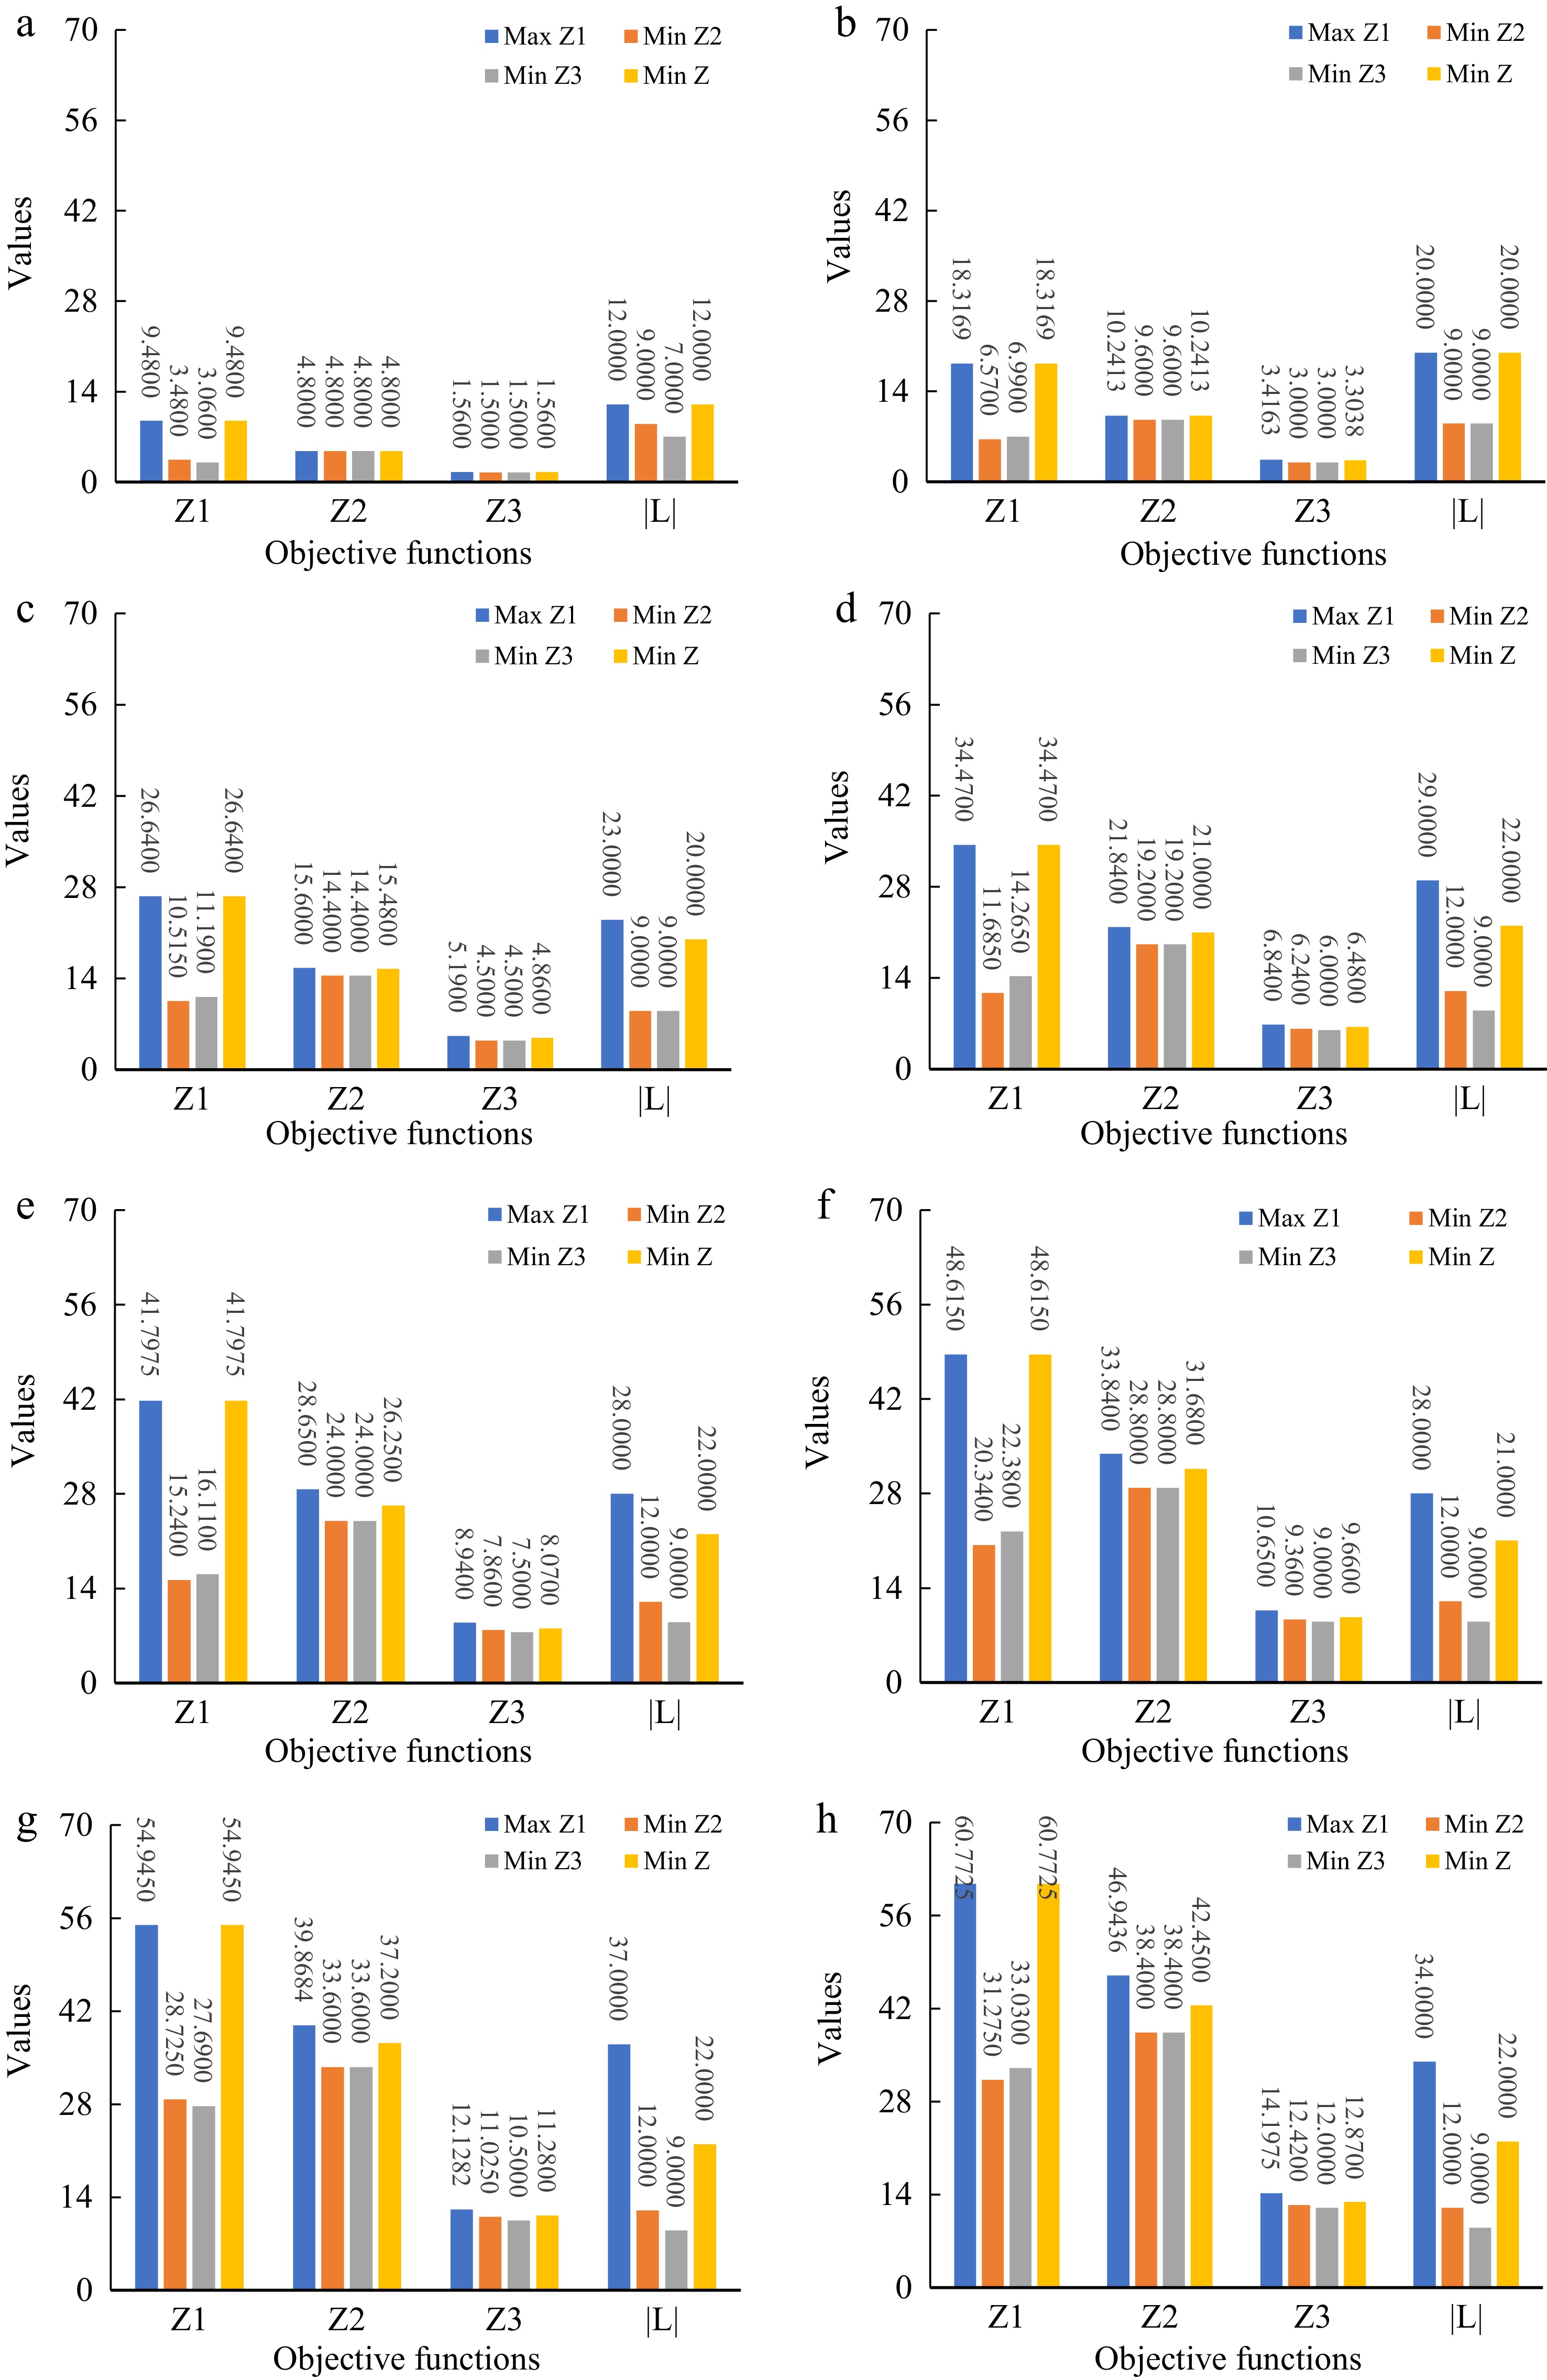
Figure 5.
Objective function values based on different optimal objectives. (a) ds = 30. (b) ds = 60. (c) ds = 90. (d) ds = 120. (e) ds = 150. (f) ds = 180. (g) ds = 210. (h) ds = 240. The unit of Z1 value is 100, the unit of Z2 value is 10,000, the unit of Z3 value is also 100, and the unit of |L| value is 1.
First, in the MOCP-RVTO problem consisting of traffic efficiency, traffic distance, and traffic distribution, if only a single objective is optimized, the other objectives are not improved. Taking Fig. 5e as an example: (1) When only max Z1 subjected to Eqs (1)–(15) is solved, the optimal value of objective function Z1 is 4,179.75; when only min Z2 subjected to Eqs (1)–(15) is solved, objective function Z1 drops to 1,524 from 4,179.75; when only min Z3 subjected to Eqs (1)–(15) is solved, objective function Z1 drops to 1,611 from 4,179.75. (2) When only min Z2 subjected to Eqs (1)–(15) is solved, the optimal value of objective function Z2 is 240,000; when only max Z1 subjected to Eqs (1)–(15) is solved, objective function Z2 increases to 286,500 from 240,000. (3) When only min Z3 subjected to Eqs (1)–(15) is solved, the optimal value of objective function Z3 is 750. When only max Z1 subjected to Eqs (1)–(15) is solved, the objective function Z3 increases to 894 from 750. When only min Z2 subjected to Eqs (1)–(15) is solved, the objective function Z3 increases to 786 from 750. Therefore, multi-objective coordination optimization among traffic efficiency, traffic distance, and traffic distribution should be focused on by the RVTO problem.
Second, because objective function Z2 has an equal value between min Z2 subjected to Eqs (1)–(15) and min Z3 subjected to Eqs (1)–(15), traffic distance minimization can also be achieved by minimizing the number of links used by rescue vehicles. For example, in Fig. 5e, when only min Z2 subjected to Eqs (1)–(15) is solved, the optimal value of the objective function Z2 is 240,000; and when only min Z3 subjected to Eqs (1)–(15) is solved, the objective function Z2 is still 240,000. However, whether link occupation minimization can be replaced by traffic distance minimization is related to rescue traffic demand: when rescue traffic demand is small (see Fig. 5b, c), traffic distance minimization can replace link occupation minimization; when rescue traffic demand is big (see Fig. 5d−h), traffic distance minimization increases the number of used links.
Third, among traffic efficiency, traffic distance, and traffic distribution of the MOCP-RVTO problem, traffic distribution defined by min Z3 subjected to Eqs (1)–(15) has the smallest number of links used by rescue vehicles, and traffic efficiency has the biggest number of links used by rescue vehicles. As shown in Fig. 5e, when only max Z1 subjected to Eqs (1)–(15) is solved, |L| is 28; when only min Z2 subjected to Eqs (1)–(15) is solved, |L| drops to 12 from 28; when only min Z3 subjected to Eqs (1)–(15) is solved, |L| further drops to 9 from 12. The results mean min Z3 subjected to Eqs (1)–(15) is suitable to minimize the number of links used by rescue vehicles, and min Z2 subjected to Eqs (1)–(15) can be replaced by min Z3 subjected to Eqs (1)–(15); however, the quick arrival of rescue vehicles in the disaster position may not be realized.
Fourth, without delaying the quick arrival of rescue vehicles at the disaster site, the MOCP can reduce the traffic distance of rescue vehicles and the number of used links on the road network. Taking Fig. 5e as an example, the value of objective function Z1 obtained by min Z is 4,179.75 and is equal to the value obtained by max Z1, but the number of used links drops to 22 from 28, and the traffic distance drops to 262,500 from 286,500. Compared to min Z2 and min Z3, traffic distance and link occupation increase, but traffic efficiency has an improvement in min Z. Obviously, the MOCP can achieve better coordination among traffic efficiency, traffic distance, and traffic distribution of the RVTO problem.
Objective weight optimization performance analysis
-
By solving the NLWSO-RVTO formulation, we further present the heuristic values of the weight coefficient decision variables of max Z in Table 4. As shown in Table 4, with the change of rescue traffic demand among 30, 60, 90, 120, 180, 210, and 240, the values of a1, a2, and a3 are approximately 0.9918, 0.0050, and 0.0032, and remain unchanged. When rescue traffic demand is 150, the values of a1, a2, and a3 change to 0.9897, 0.0070, and 0.0033.
Table 4. Objective weight optimization results.
Weight ds = 30 ds = 60 ds = 90 ds = 120 ds = 150 ds = 180 ds = 210 ds = 240 a1 0.9918 0.9918 0.9918 0.9918 0.9897 0.9918 0.9918 0.9918 a2 0.0050 0.0050 0.0050 0.0050 0.0070 0.0050 0.0050 0.0050 a3 0.0032 0.0032 0.0032 0.0032 0.0033 0.0032 0.0032 0.0032 Considering the above-listed change of objective weight values, we further input the combination weights of 0.9918, 0.0050, and 0.0032 into the NLWSO-RVTO formulation to obtain and compare the values of Z1, Z2, Z3, |L|, and Z in the scenario of ds = 150. As shown in Table 5, with the change of weight coefficients from 0.9879, 0.0070, and 0.0033 to 0.9918, 0.0050, and 0.0032, although the value of Z increases to −0.97838 from −0.98298 and presents a non-optimal objective function value, the values of Z1, Z2, Z3, and |L| do not change. Therefore, the combination weights of 0.9918, 0.0050, and 0.0032 are also the optimal weight values in the scenario of ds = 150 among traffic efficiency, traffic distance, and traffic distribution. These results mean there exists a fixed optimal combination weight among 3T, and traffic efficiency has the significantly largest weight value. Moreover, the fixed values are approximately 0.9918, 0.0050, and 0.0032.
Table 5. Objective function optimization results with ds = 150.
Objectives Combination weights (a1, a2, a3) (0.9918, 0.0050, 0.0032) (0.9897, 0.0070, 0.0033) Z1 4,179.75 4,179.75 Z2 262,500 262,500 Z3 807 807 |L| 22 22 Z −0.97838 −0.98298 Rescue link choice optimization result analysis
-
In this section, we analyze rescue vehicle traffic route choice characteristics based on SO-RVTO results of 3T and NLWSO-RVTO results of MOCP; therefore, Fig. 6 presents total rescue vehicle traffic volume assignment results on the road network.
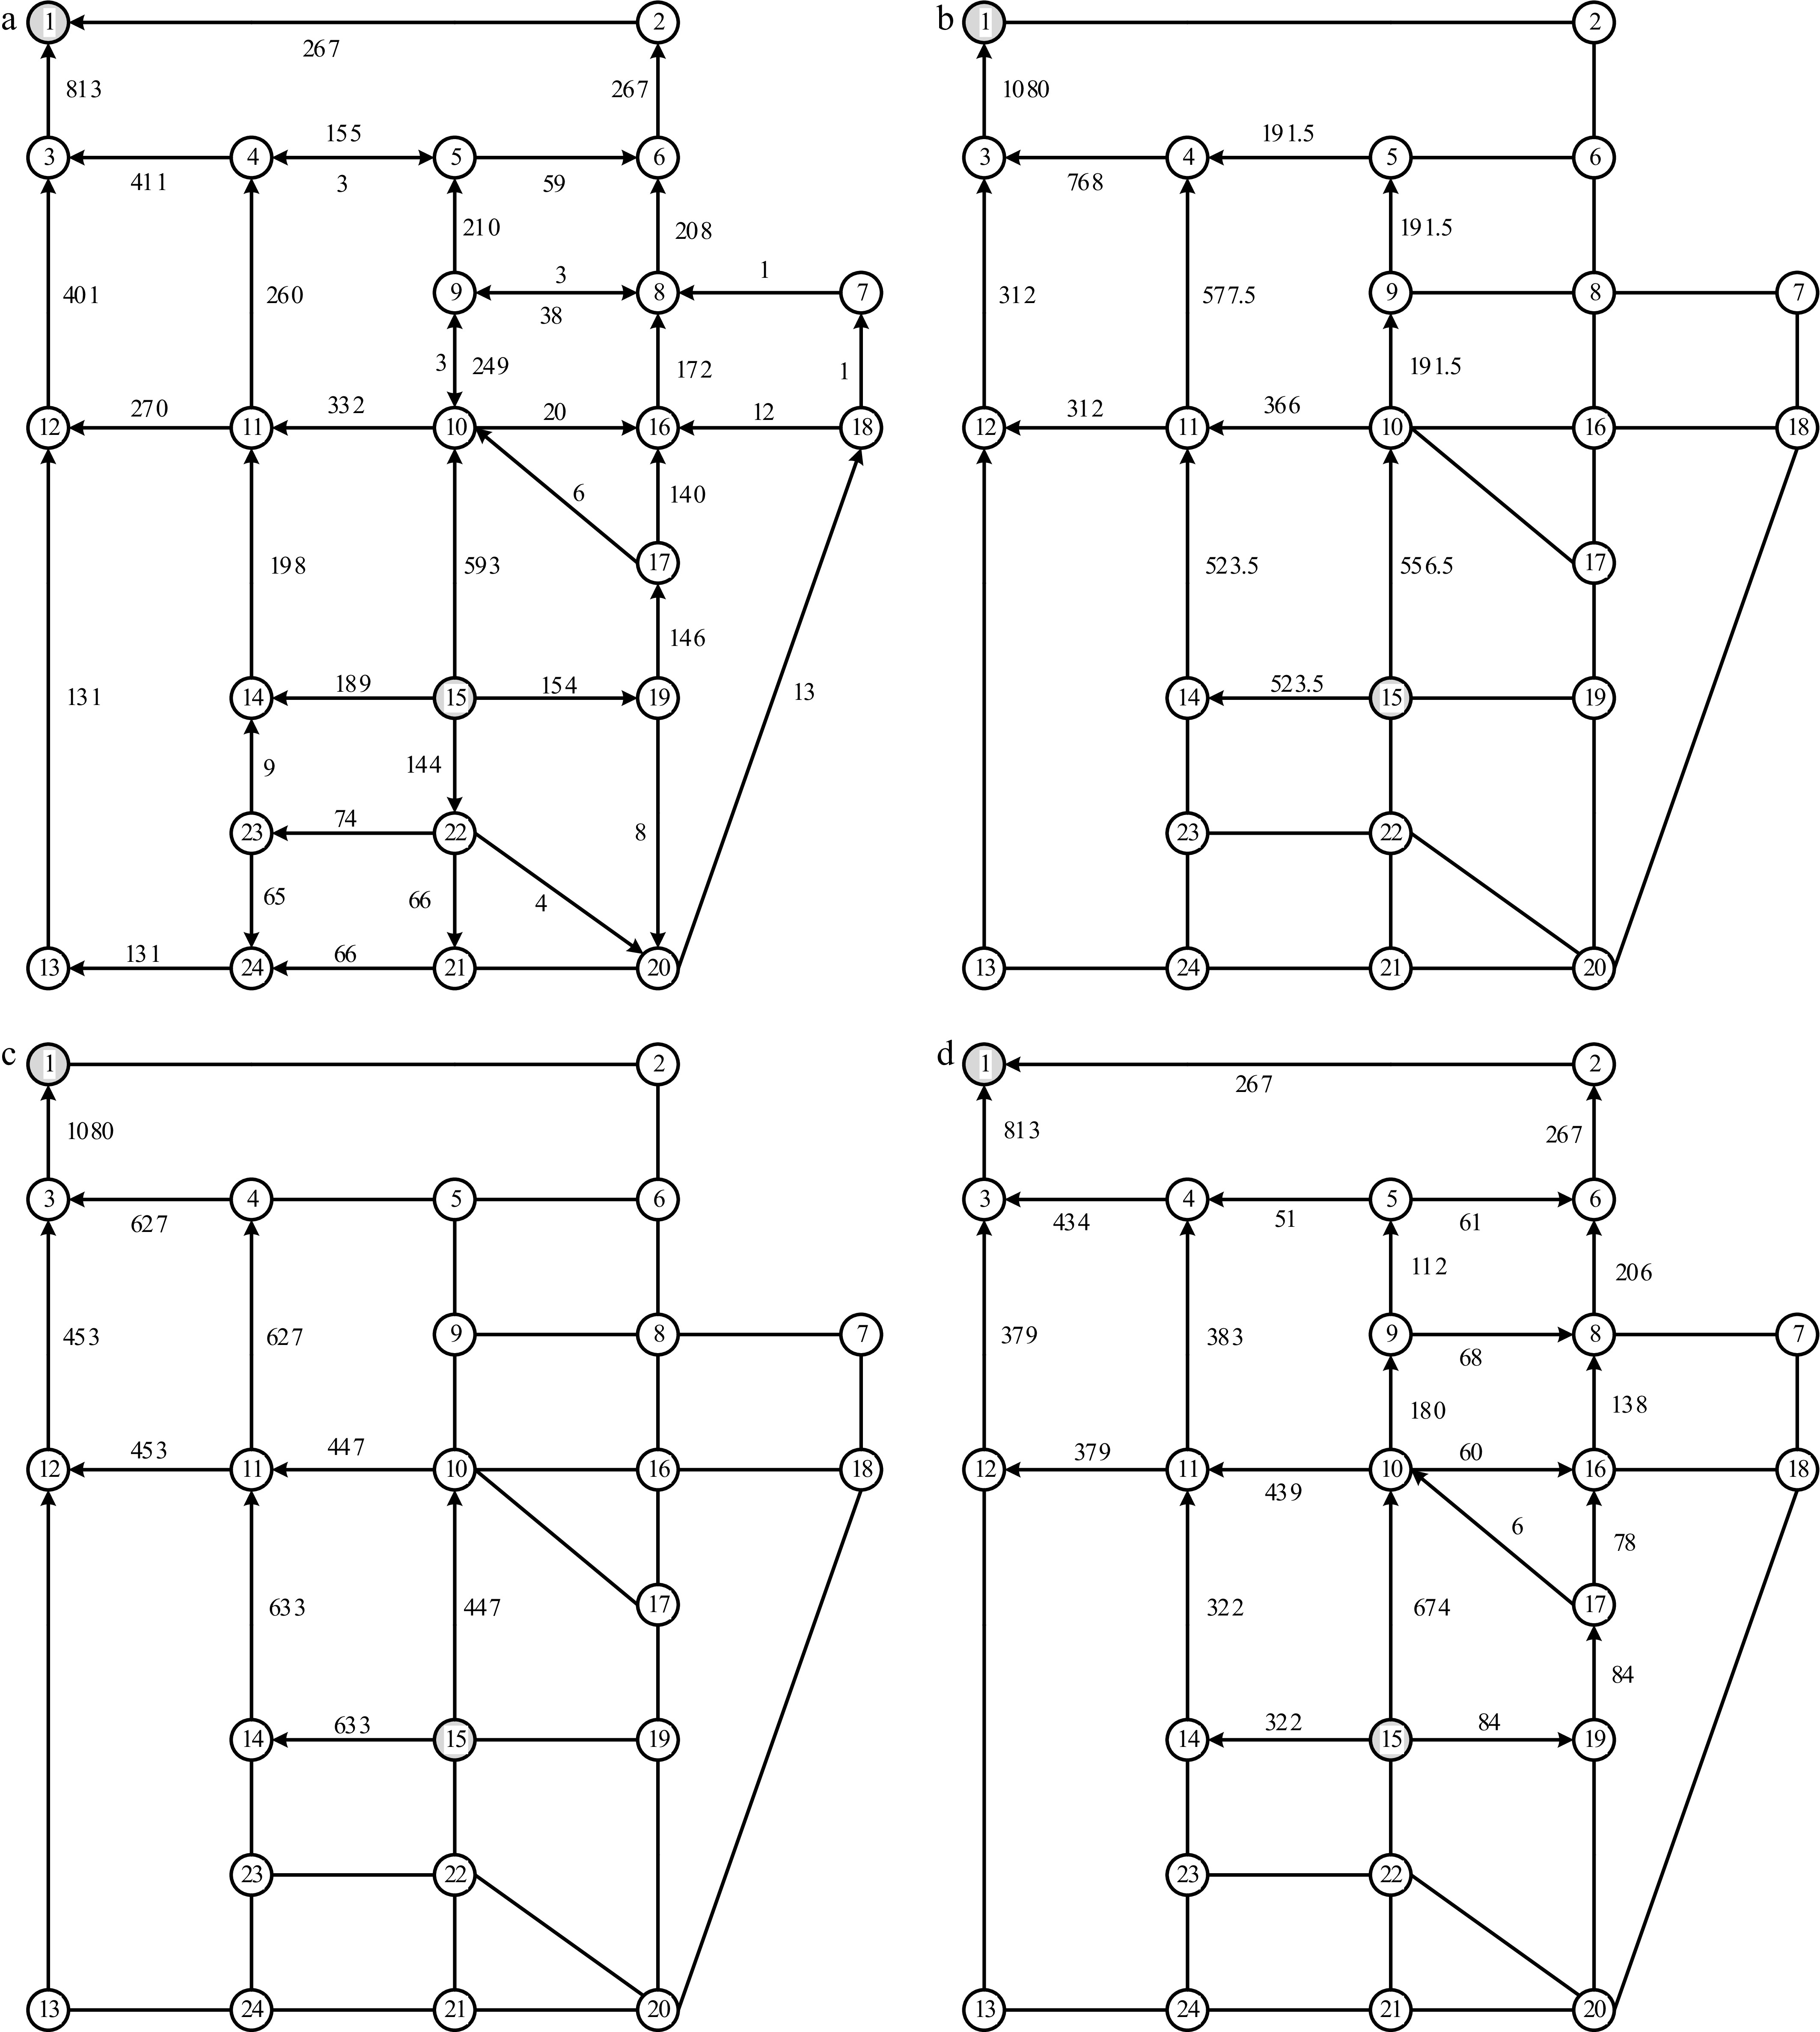
Figure 6.
Total rescue vehicle traffic volumes assigned to roads. (a) Max Z1. (b) Min Z2. (c) Min Z3. (d) Min Z.
As shown in Fig. 6, the numbers of used links are 38 of max Z1, 12 of min Z2, 9 of min Z3 and 23 of min Z. We can conclude that: (1) the optimization objective affects the number of links used by rescue vehicles in the RVTO problem; (2) 'the quick arrival of rescue vehicles at the disaster position' may cause more links be occupied by rescue vehicles, and the introduction of traffic distance optimization objective min Z2 and traffic distribution optimization objective min Z3 can reduce the number of used linked and does not delay the quick arrival of rescue vehicles in the disaster position; (3) traffic distribution described by min Z3 can obtain the smallest used links.
Dedicated rescue link opening restriction analysis
-
In the disaster emergency rescue response practice, the penetration of rescue vehicles occupies some roads. Here, we define the used links by rescue vehicles in Fig. 6 as dedicated rescue links, and further restrict the opening of these dedicated rescue links to social vehicles. In Fig. 7, the Sioux Falls road network presented in Fig. 3 is developed by Paramics software, and there exist five social vehicle traffic zones labeled as Zone 001, Zone 002, Zone 003, Zone 004, and Zone 005 on the Paramics simulation network. In Table 6, we give the OD (Origin-Destination) matrix of social vehicles among the above-listed five traffic zones. In addition, we conduct 30-min Paramics traffic simulations to simulate social vehicle traffic operation on the road network by setting different dedicated rescue link opening restrictions.
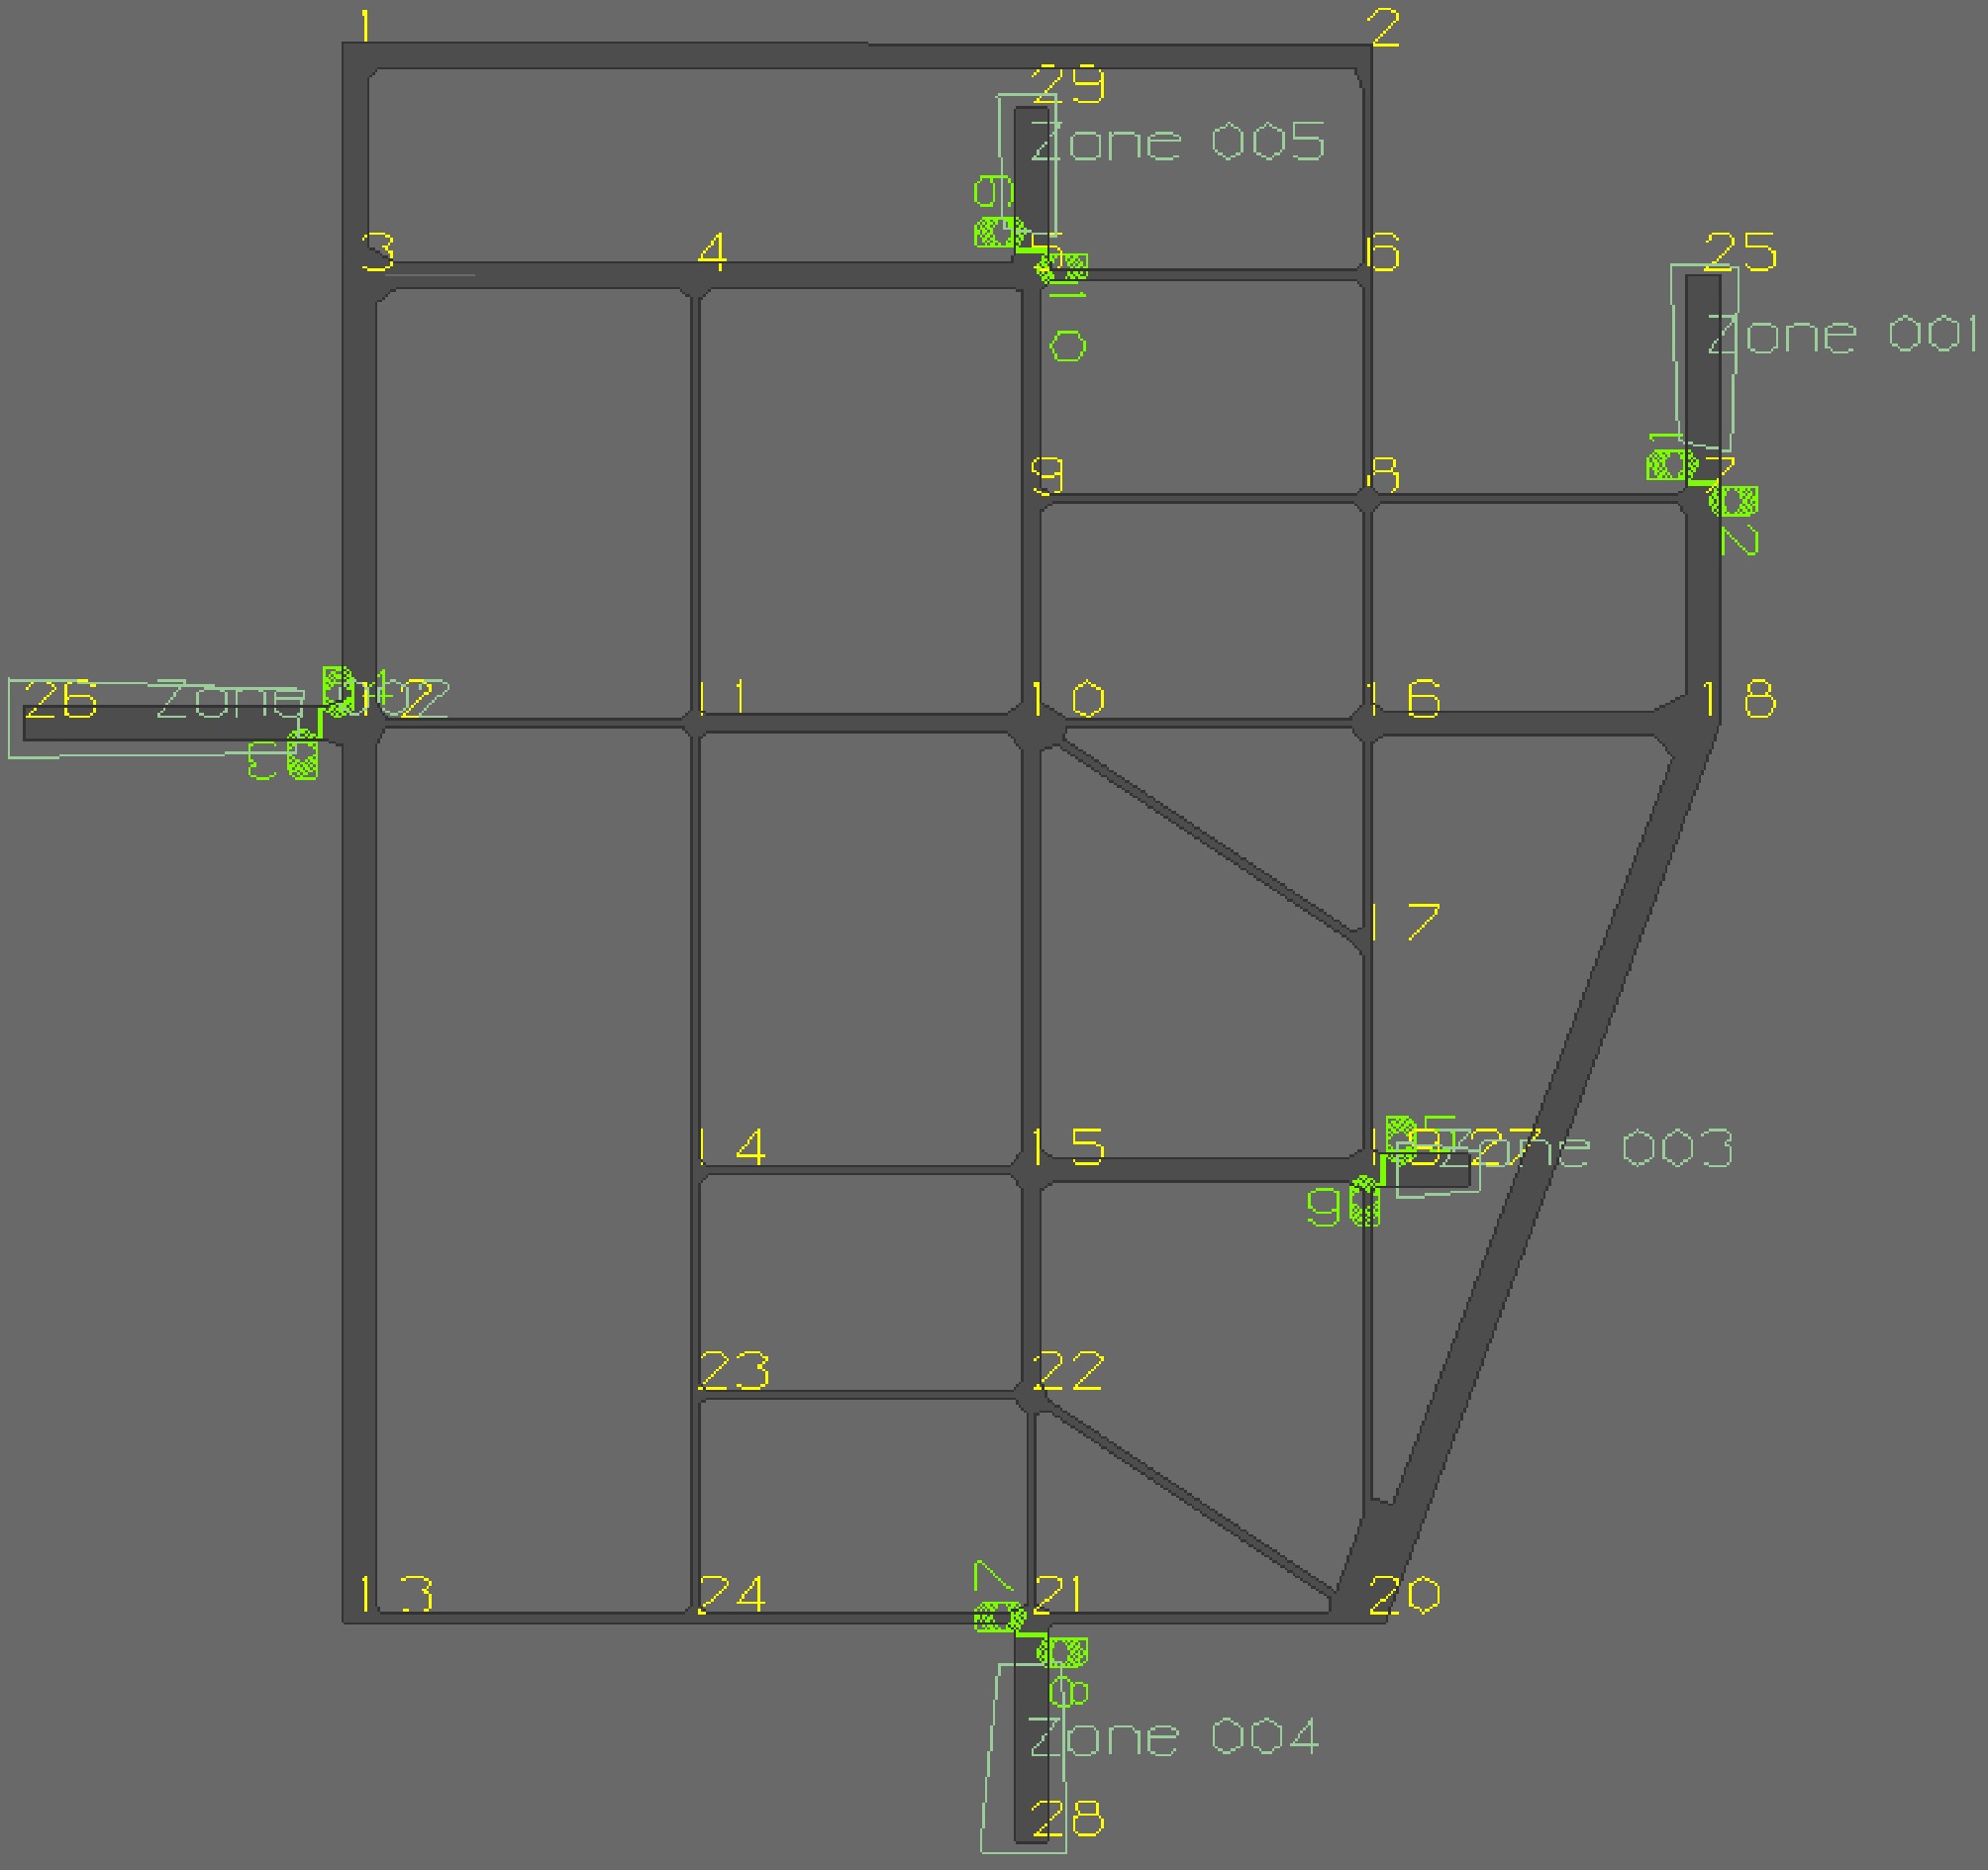
Figure 7.
Sioux Falls Paramics social vehicle traffic simulation network.
Table 6. OD matrix of social vehicles (unit: vehicles).
Origin index Destination index Zone 001 Zone 002 Zone 003 Zone 004 Zone 005 Zone 001 − 300 500 300 500 Zone 002 500 − 500 300 500 Zone 003 500 300 − 300 500 Zone 004 500 300 500 − 500 Zone 005 500 300 500 500 − In Fig. 8, we test five dedicated rescue link opening restriction scenarios: 'Benchmark' is the reference standard and refers to there being no dedicated rescue links on the road network; 'Max Z1' refers to the links obtained by solving Max Z1 subjected to Eqs (1)–(15) is defined as dedicated rescue links and social vehicles are prohibited from occupying them; 'Min Z2' refers to the links obtained by solving Min Z2 subjected to Eqs (1)–(15) is defined as dedicated rescue links; 'Min Z3' refers to the links obtained by solving Min Z3 subjected to Eqs (1)–(15) is defined as dedicated rescue links; 'Min Z' refers to the links obtained by solving Min Z subjected to Eqs (1)–(17) is defined as dedicated rescue links. In addition, 'vehicle generation' represents the total number of social vehicles departing from traffic zones, 'vehicle arrival' represents the total number of social vehicles arriving in the disaster position, and 'vehicle in transit' represents the total number of social vehicles stranded on roads at the end of the traffic simulation.
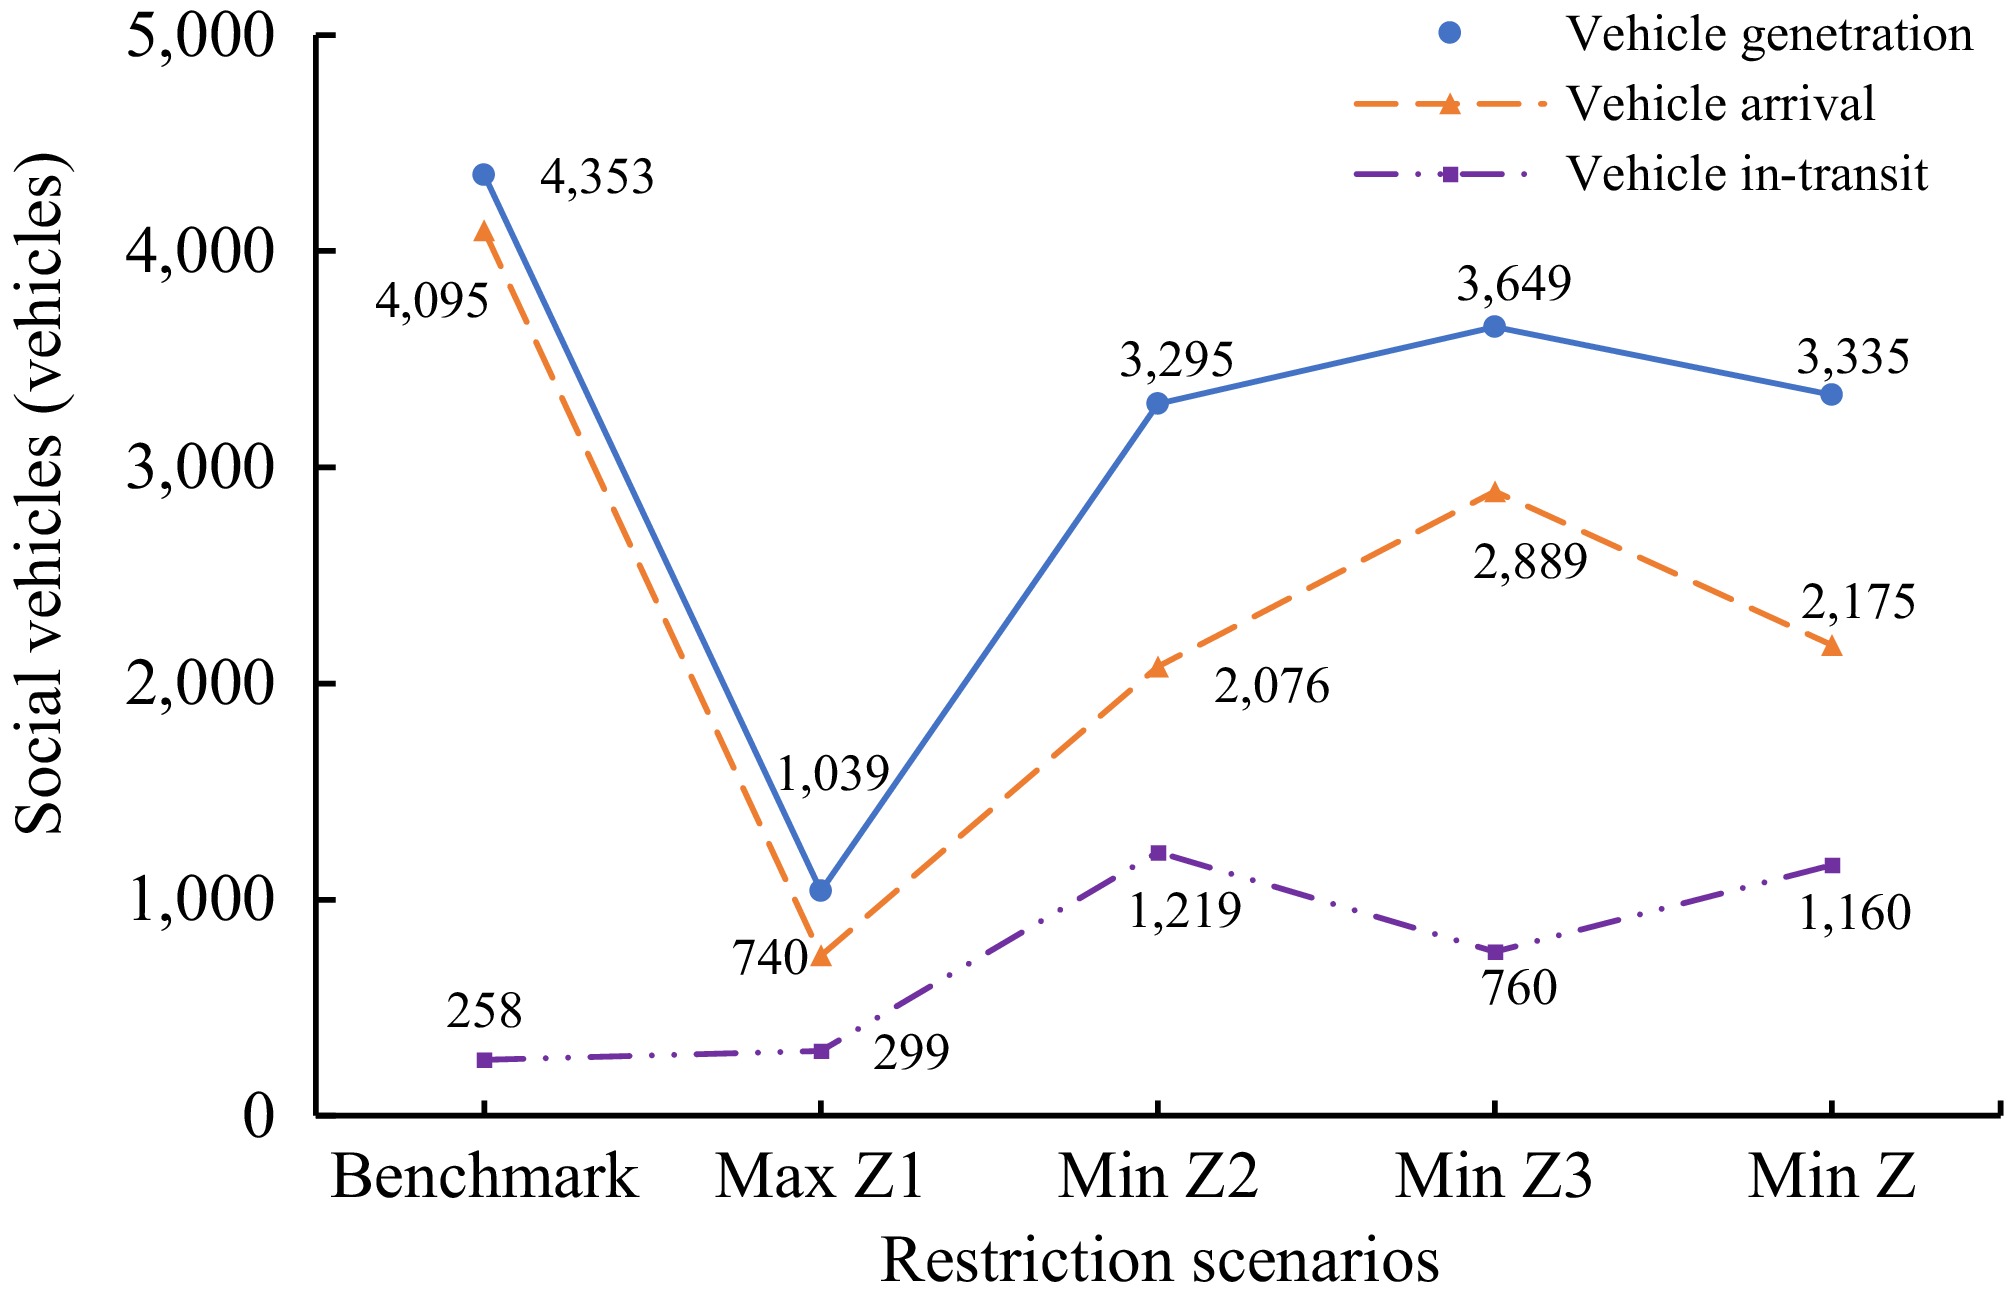
Figure 8.
Number of social vehicles.
As shown in the Paramics traffic simulation result data in Fig. 8, the benchmark scenario has the biggest social vehicle generation-arrival value, the fewest in-transit social vehicles, and the max Z1 scenario has the smallest social vehicle generation-arrival value, and the max Z scenario has a medium social vehicle generation, arrival, and in-transit value. Therefore, the result means: (1) dedicated rescue link opening restriction reduces social vehicle traffic operation efficiency and hinders the departure of social vehicles from traffic zones and their arrival at the destinations; (2) the interference is related to the number of dedicated rescue links, and the quick arrival of rescue vehicles at the disaster position has the strongest interference; (3) if traffic distance and traffic distribution are introduced into traffic efficiency, muti-objective coordination optimization among 3T can decrease the interference of dedicated rescue link opening restriction on social vehicle traffic operation and does not delay the quick arrival of rescue vehicles at the disaster position.
-
This paper explored a multi-objective combinational programming of the rescue vehicle traffic optimization problem among traffic efficiency, traffic distance, and traffic distribution by developing the MOCP-RVTO formulation and analyzing the impact of the dedicated rescue link opening restriction on social vehicle traffic operation. Here, we designed a GAD-based solving approach to solve this MOCP-RVTO formulation, and adopted Paramics to simulate social vehicle traffic operation on the classical Sioux Falls road network. Some novel findings that can realize the quick arrival of rescue vehicles at the disaster position and reduce the interference of rescue vehicle traffic operation on social vehicle traffic travel are captured:
(1) In the RVTO problem consisting of traffic efficiency, traffic distance, and traffic distribution, single-objective optimization does not realize coordinative optimization of other objectives, and thus multi-objective coordination optimization should be focused on; the MOCP can achieve a better coordination among traffic efficiency, traffic distance, and traffic distribution.
(2) Traffic distance minimization can be achieved by minimizing the number of links used by rescue vehicles; however, whether link occupation minimization can be replaced by traffic distance minimization is related to rescue vehicle traffic demand: when traffic demand is small, the replacement is flexible.
(3) Traffic efficiency results in more links being occupied by rescue vehicles, but traffic distance and traffic distribution can reduce the number of links used by rescue vehicles. Therefore, without delaying the quick arrival of rescue vehicles at the disaster position, the MOCP can reduce the traffic distance of rescue vehicles and the number of links used on the road network.
(4) There exists a fixed optimal combination weight value among traffic efficiency, traffic distance, and traffic distribution in the MOCP-RVTO problem, in which traffic efficiency has the significantly biggest weight and traffic distribution has the smallest weight.
(5) Dedicated rescue link opening restriction interferes social vehicle traffic travel, and the level of the interference is related to the number of dedicated links:
1) Dedicated rescue link opening restriction reduces social vehicle traffic operation efficiency and hinders the departure of social vehicles from traffic zones and their arrival at the destinations. Moreover, the quick arrival of rescue vehicles at the disaster position has the strongest interference;
2) If traffic distance and traffic distribution are introduced into traffic efficiency, multi-objective coordination programming among 3T can decrease the interference of dedicated rescue link opening restriction on social vehicle traffic operation and does not delay the quick arrival of rescue vehicles at the disaster position.
Our studies have an important application for rescue vehicle traffic optimization by considering social vehicle traffic operation in the phase of disaster emergency rescue response; for example, planning rescue vehicle traffic routes to ensure the quick arrival of rescue vehicles and reduce interference to rescue traffic priority on social vehicle traffic operation. In addition, considering that the LTM-based dynamic rescue traffic network loading has a quite large solving scale and causes the algorithm design to have low solving efficiency, on the basis of this work, one of the future directions is how to integrate artificial intelligence (e.g., deep reinforcement learning) to improve the solving efficiency of the MOCP-RVTO problem.
-
The author confirms sole responsibility for all aspects of this study and approved the final version of the manuscript.
-
The datasets generated during and/or analyzed during the current study are available from the corresponding author on reasonable request.
-
The author has no known competing financial interests or personal relationships that could have appeared to influence the work reported in this paper.
- Copyright: © 2026 by the author(s). Published by Maximum Academic Press, Fayetteville, GA. This article is an open access article distributed under Creative Commons Attribution License (CC BY 4.0), visit https://creativecommons.org/licenses/by/4.0/.
-
About this article
Cite this article
Liu Z. 2026. Multi-objective rescue vehicle traffic optimization with dedicated link opening restriction. Digital Transportation and Safety 5(3): 237−247 doi: 10.48130/dts-0026-0019 
Multi-objective rescue vehicle traffic optimization with dedicated link opening restriction
- Received: 06 May 2026
- Revised: 20 June 2026
- Accepted: 14 July 2026
- Published online: 30 September 2026
Abstract: In disaster emergency rescue response, rescue vehicle traffic often interferes with social vehicle traffic on roads, and rescue vehicle traffic optimization (RVTO) is always related to traffic efficiency, traffic distance, and traffic distribution (3T). Here, we develop a multi-objective combinatorial programming (MOCP) formulation of the RVTO problem, and transform MOCP-RVTO into a nonlinear weighted single-objective RVTO (NLWSO-RVTO) problem by introducing objective weight decision variables. We then design a genetic algorithm decomposition (GAD) solving approach to realize multi-objective coordination and importance analysis among the 3T. Moreover, the impact of a multi-objective dedicated rescue link opening restriction on social vehicle traffic is analyzed using Paramics. The case test on the Sioux Falls network shows that introducing traffic distance and traffic distribution into traffic efficiency can reduce the number of used rescue links, and link occupation minimization can replace traffic distance minimization to reduce used rescue links and traffic distance. There exists an optimal constant combination weight value among 3T in which traffic efficiency has the significantly greatest importance and traffic distribution has the smallest weight. 3T combinatorial optimization does not delay the quick arrival of rescue vehicles at the disaster position and can synchronously decrease the interference of dedicated rescue links on social vehicle traffic operation.